DRG 80-90-AS
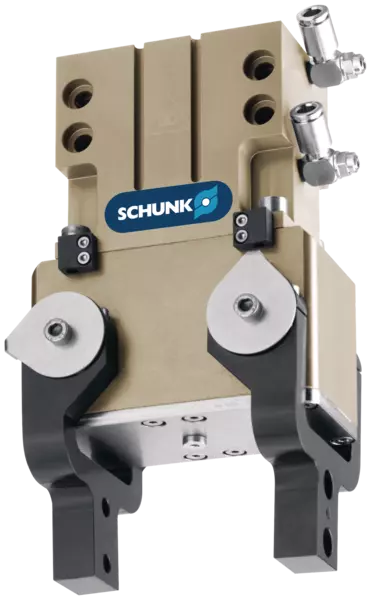
Radial gripper
ID 307109
Radial gripper DRG, Size: 80, pneumatic, with gripping force maintenance: AS (spring-closing)
- Opening angle: 90 °
- Closing moment: 50 Nm
- Max. ambient temperature: 90 °C
Technical details
| Closing force (with finger lengths of 0 mm) [N] | 1694.0 |
|---|---|
| Opening angle per jaw [°] | 90.0 |
| Closed angle per jaw [°] | 1.5 |
| Closing moment [Nm] | 50.0 |
| Closing moment generated by spring [Nm] | 8.1 |
| Weight [kg] | 2.0 |
| Recommended workpiece weight [kg] | 3.2 |
| Cylinder volume per double stroke [cm³] | 110.0 |
| Min. operating pressure [bar] | 4.0 |
| Max. operating pressure [bar] | 6.5 |
| Nominal operating pressure [bar] | 6.0 |
| Closing time [s] | 0.5 |
| Opening time [s] | 0.6 |
| Closing time with spring only [s] | 0.7 |
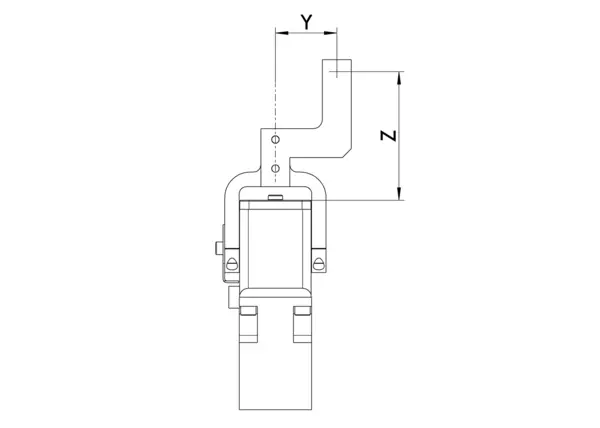
| Max. permissible finger length [mm] | 100.0 |
| Max. permissible weight per finger [kg] | 0.5 |
| IP protection class | 67 |
| Min. ambient temperature [°C] | 5.0 |
| Max. ambient temperature [°C] | 90.0 |
| Repeat accuracy [mm] | 0.1 |
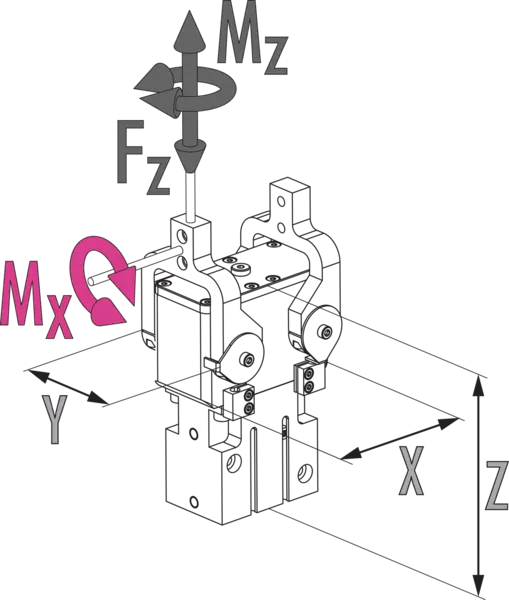
| Length X [mm] | 100.0 |
| Width Y [mm] | 71.6 |
| Height Z [mm] | 135.5 |
| Moment Mx max. [Nm] | 17.5 |
| Moment Mz max. [Nm] | 1.6 |
| Max. axial force Fz max. [N] | 400.0 |
The opening angle of the base jaws can be limited.
尺寸和最大载荷
最大允许手指投影
Gripping force O.D. gripping
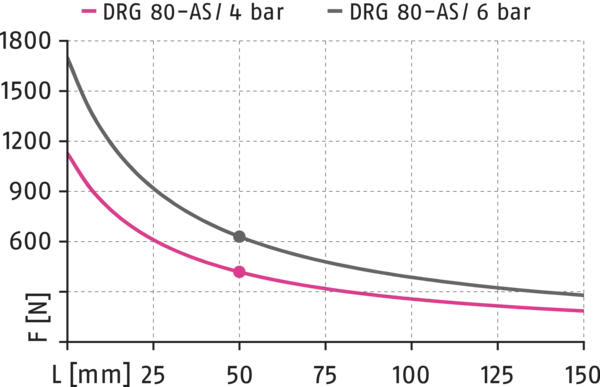
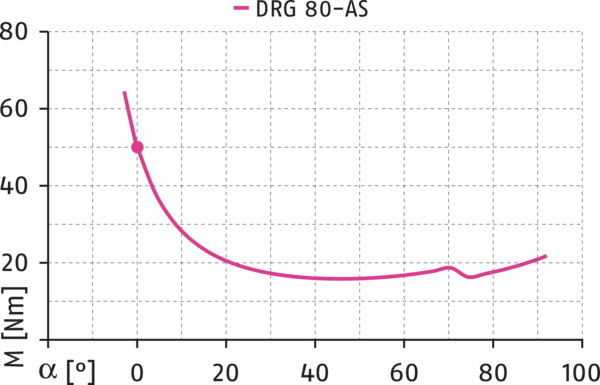
闭合力矩曲线
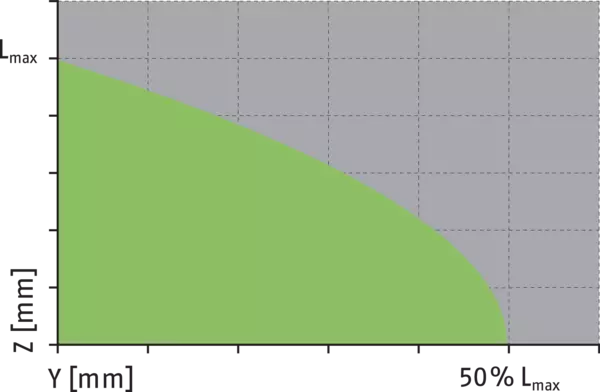
最大允许手指投影
尺寸和最大载荷
所示力矩和力为静态值,作用于每个基爪,不能同时存在。
最大允许手指投影
Gripping force O.D. gripping
- X-axis:
- Point P - Finger length
- Y-axis:
- Gripping force
闭合力矩曲线
- X-axis:
- 张开角度
- Y-axis:
- 闭合力矩
最大允许手指投影
Lmax 等于最大允许手指长度。请参见技术参数表。
- green
- 允许的范围
- grey
- 不允许的范围
产品系列的常规说明
闭合力矩
施加到每个机械手夹爪的抓取力矩的算术和。 张开角度为 0° 时,达到指示的闭合力矩。闭合力矩随张角的变化可参照下图“闭合力矩路线”
手指长度
沿主轴方向,从距基准面距离 P 处测得。
重复精度
定义为 100 个连续行程后极限位置分布。
工件重量
采用摩擦系数 0.1 和安全系数(防止由于重力加速 g 工件滑落) 2 计算压入配合抓取。如果是适形或捕获式抓取,可抓取工件重量则大很多。
闭合/打开时间
仅是基爪的移动时间,不含特定应用的机械手手指。不包括阀门开关时间、软管注入时间或 PLC 反应时间,但是计算周期时必须考虑这些时间。
工作原理
楔式结构
外壳材料
铝合金,阳极氧化
基爪材料
钢
启动
气动,带符合 ISO 8573-1:2010 [7:4:4] 的过滤压缩空气。
保修期
24 个月
使用寿命特性
根据要求
标配范围
所订购的机械手、附件包(定心套筒,用于直接连接的 O 型圈/详细内容请参见操作手册)和安全信息。对应的产品说明书,可以前往 schunk.com/downloads-manuals 下载。
抓取力保持
始终采用弹簧集成,还可通过保压阀 SDV-P 实现