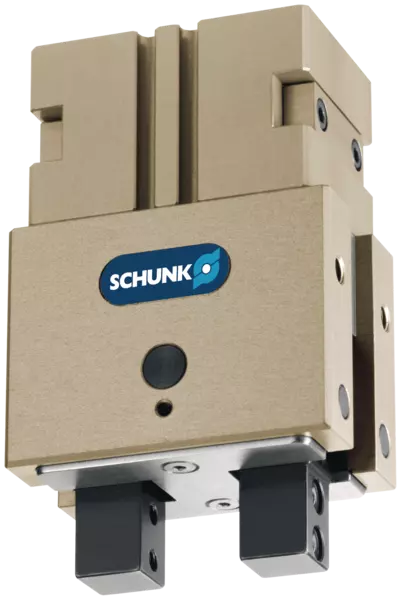
GAP 28-030-S
ID 314616
- Stroke per jaw: 1.5 mm
- Closing force: 180 N
- Opening angle: 30 °
- Max. ambient temperature: 60 °C
Technical details
| Stroke per jaw [mm] | 1.5 |
|---|---|
| Closing force [N] | 180.0 |
| Closing force (with finger lengths of 0 mm) [N] | 214.0 |
| Opening angle per jaw [°] | 30.0 |
| Weight [kg] | 0.58 |
| Recommended workpiece weight [kg] | 0.9 |
| Cylinder volume per double stroke [cm³] | 6.5 |
| Min. operating pressure [bar] | 3.0 |
| Max. operating pressure [bar] | 7.0 |
| Nominal operating pressure [bar] | 6.0 |
| Closing time [s] | 0.13 |
| Opening time [s] | 0.13 |
| Max. permissible finger length [mm] | 50.0 |
| Max. permissible weight per finger [kg] | 0.17 |
| Max. permissible inertia per chuck jaw [kgcm²] | 7.45 |
| IP protection class | 40 |
| Min. ambient temperature [°C] | 5.0 |
| Max. ambient temperature [°C] | 60.0 |
| Repeat accuracy [mm] | 0.05 |
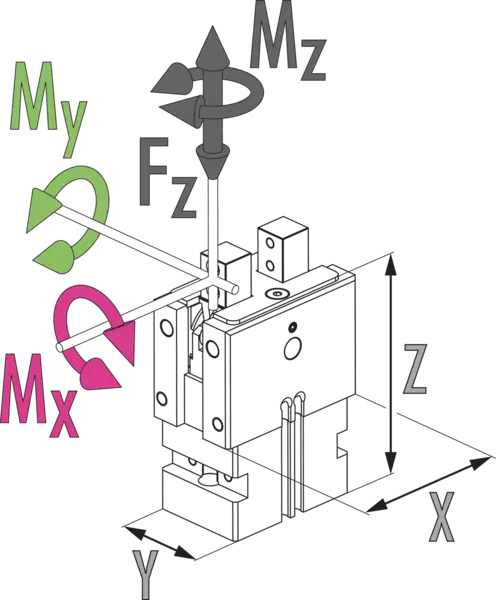
| Moment Mx max. [Nm] | 8.6 |
| Moment My max. [Nm] | 8.4 |
| Moment Mz max. [Nm] | 2.2 |
| Max. axial force Fz max. [N] | 360.0 |
| Shock absorber version | yes |
Dimensions and maximum loads
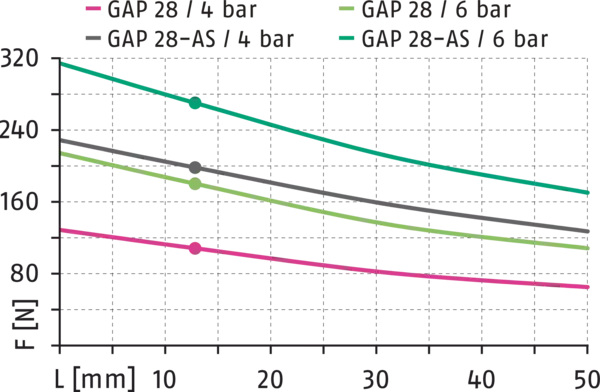
Gripping force O.D. gripping
Max. permissible inertia J*

Dimensions and maximum loads
The indicated moments and forces are statical values, apply for each base jaw and may appear simultaneously. Loads may additionally occur to the moment produced by the gripping force itself.
Gripping force O.D. gripping
- X-axis:
- Point P - Finger length
- Y-axis:
- Gripping force
Max. permissible inertia J*
- X-axis:
- Closing/opening time
- Y-axis:
- Inertia
General notes about the series
Closing moment
is the arithmetic sum of the individual moment applied to each jaw.
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy
is defined as a distribution of the end Position for 100 consecutive strokes.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing and opening times
are movement times of the base jaws only, without application-specific gripper fingers. Valve switching times, hose fill times, or PLC reaction times are not included, and are to be considered when cycle times are calculated.
Wirkprinzip
Zwangsgeführte Kniehebelkinematik
Gehäusematerial
Aluminiumlegierung, eloxiert
Grundbackenmaterial
Stahl
Betätigung
pneumatisch, über gefilterte Druckluft nach ISO 8573-1:2010 [7:4:4]
Gewährleistung
24 Monate
Lebensdauerkennwerte
auf Anfrage
Lieferumfang
Greifer in der bestellten Variante, Beipack (Zentrierhülsen, O-Ringe für Direktanschluss / detaillierter Inhalt siehe Betriebsanleitung) und Sicherheitsinformationen. Produktspezifische Anleitungen können unter schunk.com/downloads-manuals heruntergeladen werden.
Greifkrafterhaltung
über Variante mit mechanischer Greifkrafterhaltung oder Druckerhaltungsventil SDV-P möglich