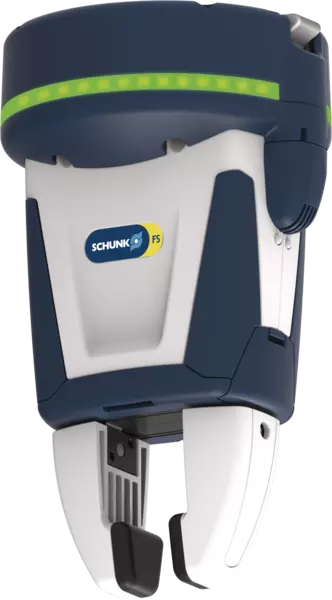
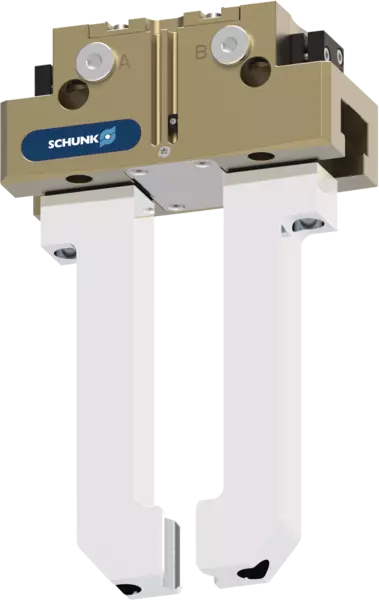
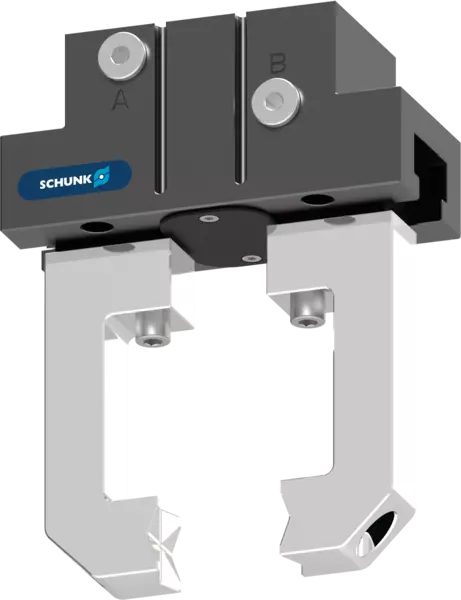
The ambient temperature describes the temperature of the air or the direct operating environment in which a gripper is operated (and not the workpiece temperature, as this is normally significantly higher than the ambient temperature). We also offer special solutions for ambient temperatures above 130 °C. We would be happy to review your use case based on your specific process data.
is calculated for force-fit clamping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. In the case of form-fit gripping, significatnly higher permissible workpiece weights are possible.
Example: - For the catalog-specified workpiece weight of 5 kg Gripping force of the gripper 1,000 N Coefficient of friction μ 0.1; safety factor 2; g 9.81
For supported robot systems, we provide specific adapter plates, cable kits, and software plug-ins. This simplifies a standardized mechanical connection as well as software commissioning and integration. Is your target system not listed? Please contact us!
For supported control systems, we provide specific software resources (e.g., function blocks or parameter sets). This simplifies software commissioning and integration. Is your target system not listed? Please contact us!