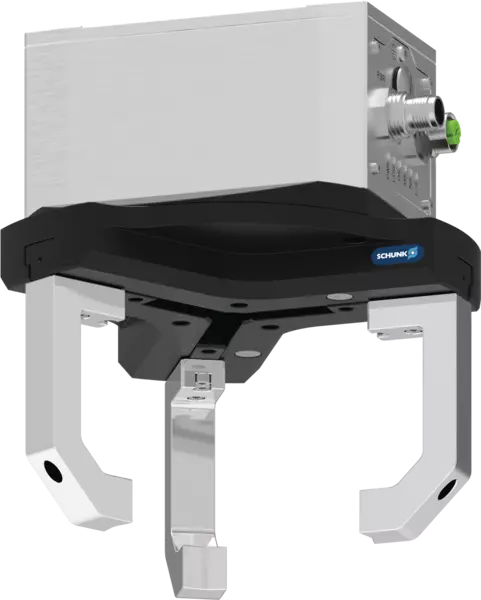
EZU
Fonction
Sectional diagram

Sectional diagram
The brushless DC servomotor drives the three gear racks integrated in the slide-guided base jaws via a spur gear unit with rack-and-pinion principle. The spur gear unit reliably generates the gripping force, which remains constant even in the event of horizontal positioning errors of the workpiece or robot, thereby ensuring reliable centering of the workpiece as well as a high fault tolerance. The gripping force is generated without a minimum approach distance, which simplifies handling and speeds up the process.
An integrated absolute encoder ensures that the gripper is immediately ready for use even after an emergency stop or power failure. The gripping force maintenance, which is achieved in combination with a permanent magnet brake and a damping element in the drive train, reduces the risk of workpiece loss, which is detected by the integrated workpiece loss detection.
- 1
-
Sturdy and resistant T-slot guidance
for large finger lengths, external forces and moments. Optionally available as dust-tight version. - 2
-
Fully integrated and sealed control and power electronics
with status LEDs and M12 plug connectors for connecting the voltage supply and communication. - 3
-
High-resolution, output-side absolute encoder
for precise positioning of the gripper jaws with permanent absolute position feedback. - 4
-
Sealed drive train with spur gear and pinion/rack principle
enables reliable generation of the gripping force without a minimum approach distance. - 5
-
Brushless flat motor
for limited space and high torques due to external rotor. - 6
-
Electromagnetic brake
with additional mechanism for maintaining gripping force and position during standstill or power failure.
Commissioning app in the SCHUNK control center
Increased protection class with dust-tight version SD

Option de montage pour une fixation supplémentaire

Connectivité
Greifmodi

Software Service - Roboterintegration

Software Service - SPS Integration

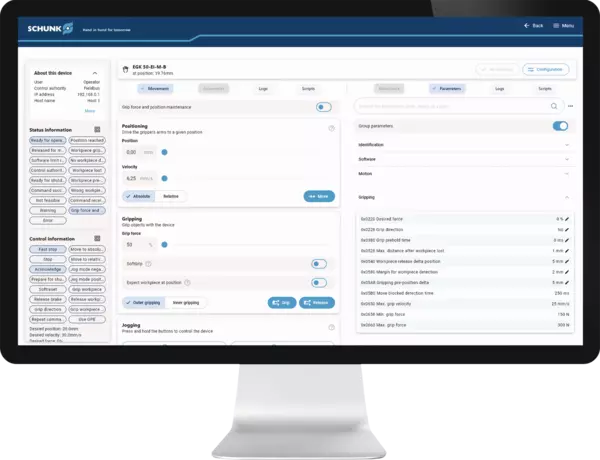
Commissioning app in the SCHUNK control center
The mechatronic grippers app simplifies commissioning, operation, diagnostics and service thanks to an extensive catalog of functions Users can control the gripper directly and perform application validation without the need for a PLC. The functions include network configuration, firmware updates, parameter adjustments and backups as well as comprehensive diagnostic options. The app is compatible with Windows and can be downloaded at schunk.com/downloads-software.
Increased protection class with dust-tight version SD
The dust-tight version increases the degree of protection against dust and liquids entering the guidance and base jaw. In combination with the sealed electronics (IP67), the dust-tight version is thus suitable for use in particularly harsh ambient conditions, such as for loading a grinding machine. The achieved protection of the guidance corresponds to the IP64 protection class and is thus absolutely dust-tight and protected against splashing water from all directions. You can find additional information on the product in the operating manual.
Option de montage pour une fixation supplémentaire
Des taraudages supplémentaires sont situés dans le corps pour le montage d'un modèle spécifique à une application afin de mettre en œuvre des fonctions supplémentaires. Par exemple, un élément de pression à ressort peut être installé pour positionner la pièce contre une butée en s'appuyant sur un ressort.
Connectivité
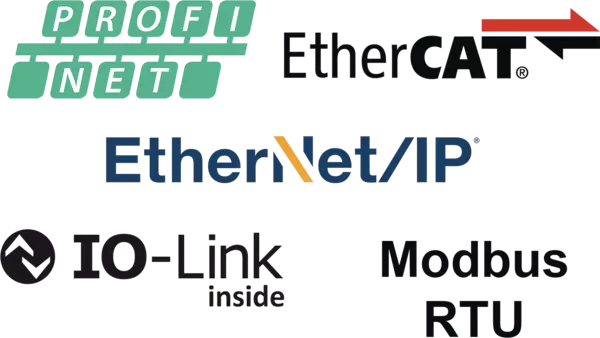
Un grand nombre d'interfaces de communication disponibles simplifie la manipulation avec une grande variété de fabricants de commandes et de robots et garantit un gain de temps lors de l'intégration. L'Ethernet industriel (PROFINET, EtherCAT, EtherNet/IP) permet une intégration directe, sans passerelle supplémentaire, dans l'environnement de contrôle des principaux fabricants d'automates du marché. Grâce à l'interface série Modbus RTU, la pince peut être connectée au poignet des principaux fabricants de robots sans besoin de câble externe. IO-Link est indépendant et offre une flexibilité dans la connexion à d'autres réseaux.
Greifmodi
Es stehen die Greifmodi BasicGrip und StrongGrip zur Verfügung.
BasicGrip: Greifgeschwindigkeit wird automatisch zur gewählten Greifkrafteinstellung optimiert, permanentes Nachgreifen ist möglich
StrongGrip: maximale Greifkraft wird erzeugt und anschließend durch die Greifkrafterhaltung gesichert, permanentes Nachgreifen ist innerhalb eines einstellbaren Zeitfensters möglich, Pausenzeiten zwischen Greifzyklen müssen berücksichtigt werden
Software Service - Roboterintegration
Für ein nahtloses Zusammenspiel zwischen Greifer und Roboter stehen Softwarebausteine für die Integration in die Robotersteuerung führender Hersteller zur Verfügung. Dadurch ist der Funktionsumfang des Greifers ohne zusätzlichen Programmieraufwand nutzbar und es kann direkt damit begonnen werden die Applikation zu programmieren.
Roboterkompatibilität: Universal Robots e-Series über Modbus RTU, FANUC CRX über Modbus RTU, ABB OmniCore C30 über EtherNet/IP, Yaskawa YRC1000micro über EtherNet/IP, Kassow Robots über Modbus RTU.
Software und weitere Kompatibilitätshinweise können unter schunk.com/downloads-software heruntergeladen werden.
Software Service - SPS Integration
Für ein nahtloses Zusammenspiel zwischen Greifer und SPS-Steuerung stehen Funktionsbausteine für die Programmieroberfläche führender Hersteller zur Verfügung. Dadurch ist der Funktionsumfang des Greifers ohne zusätzlichen Programmieraufwand nutzbar und es kann direkt damit begonnen werden die Applikation zu programmieren.
SPS-Kompatibilität: Siemens TIA Portal (PROFINET und IO-Link), Beckhoff TwinCAT (EtherCAT und IO-Link), Allen Bradley Studio 5000 Logix Designer (EtherNet/IP und IO-Link), Bosch Rexroth ctrlX (EtherCAT, nur mit Bosch Nexeed Automation).
Software und weitere Kompatibilitätshinweise können unter schunk.com/downloads-software heruntergeladen werden.
Anwendungsbeispiel

Anwendungsbeispiel
Flexibles, taktzeitoptimiertes Be- und Entladen einer Werkzeugmaschine. Durch den Einsatz von zwei Greifern am Roboter kann die automatisierte Beladung der Werkzeugmaschine taktzeitoptimierend erfolgen und dadurch die Produktivität gesteigert werden. Fertigteil und Rohteil können in einem Beladezyklus transportiert werden. Durch den großen und frei programmierbaren Backenhub des Greifers können unterschiedliche Durchmesser gegriffen werden, ohne dass der Greifer dabei ausgewechselt werden muss.
- 1
-
Doppelgreifer EZU für Roh- und Fertigteilhandling
- 2
-
Werkzeugmaschine mit Kraftspannfutter ROTA THW3