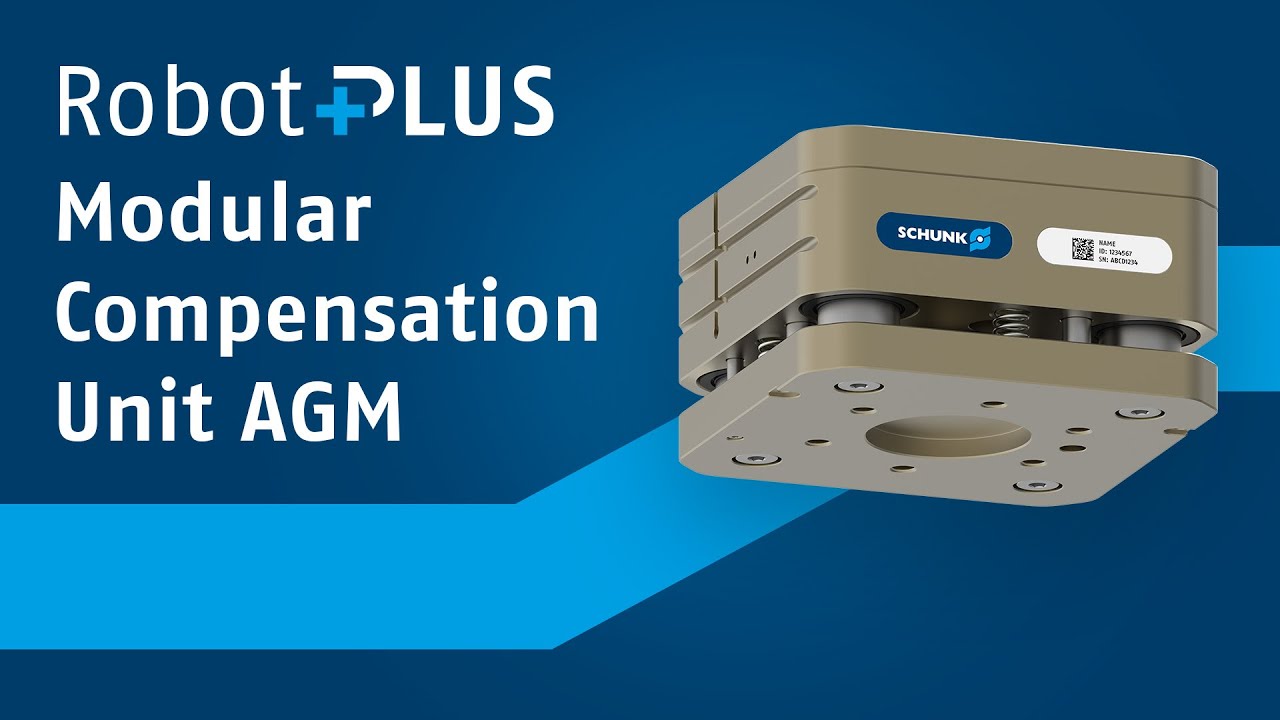

AGM-XY
Function
단면도

단면도
AGM-XY 보정 유닛은 x축과 y축에서 보정을 제공합니다. 특허받은 단일 평면 가이드 배열과 견고하고 부드럽게 작동하는 선형 롤러 가이드를 통해 최소 전체 높이로 높은 하중과 토크를 처리할 수 있습니다. 예를 들어, 통합 공압 잠금 장치와 위치 메모리를 사용하여 구성 요소의 목표 정렬을 위해 장치를 중앙 및 편심 방향으로 모두 잠글 수 있습니다. 통합 스트로크 조정을 통해 x축과 y축의 보정 이동을 개별적으로 조정할 수 있으며, 필요한 경우 완전히 고정할 수도 있습니다.
- 1
-
ISO mounting pattern
on the robot and tool side, for easy mounting on most types of robots without needing an additional adapter plate - 2
-
Locking piston
made of hardened steel for pneumatically actuated locking in centric position - 3
-
Position memory
Optional, for pneumatically actuated locking in any eccentric position - 4
-
Linear roller guides
enable maximum load capacity and smooth operation with minimal installation height - 5
-
Stroke adjustment
for mechanical, continuous adjustment or locking of the compensating stroke - 6
-
Monitoring groove
Monitoring of the locked and unlocked status with magnetic switches
Workpiece pick up (vertical, hanging): AGM unlocked – gripper opened

AGM deflected – gripper closed

AGM eccentrically locked via position memory – gripper closed

AGM centrically locked – gripper closed

AGM unlocked with spring or air cartridge – gripper closed

For comparison: AGM unlocked, without spring & air cartridge – gripper closed

AGM deflected with spring or air cartridge – gripper closed

Combined units AGM-XYZ and AGM-WZ

Workpiece pick up (vertical, hanging): AGM unlocked – gripper opened
The robot approaches the workpiece with an open gripper and the AGM (compensation unit) unlocked; the workpiece is positioned with an axis offset due to the tolerances or inaccuracies.
AGM deflected – gripper closed
The unlocked AGM can compensate for the existing axis offset between the gripper axis and the workpiece axis, ensuring that the workpiece can be gripped safely. The resulting eccentric position of the AGM can be locked/clamped by means of the integrated position memory.
AGM eccentrically locked via position memory – gripper closed
The robot picks up the workpiece and moves up.
AGM centrically locked – gripper closed
The position memory of the AGM is unlocked and the centric locking of the AGM is activated. This eliminates the previously existing axis offset, as the gripper and robot axis are now centered relative to each other.
AGM unlocked with spring or air cartridge – gripper closed
The robot moves to the drop-off position with the gripped workpiece and the AGM (compensation unit) is locked. There is an axis offset due to tolerances or inaccuracies. The AGM is unlocked for joining the workpiece. The unlocked AGM is held stable against gravity by the spring or air cartridges.
For comparison: AGM unlocked, without spring & air cartridge – gripper closed
Without a spring or air cartridge, the AGM is not stabilized against gravity and cannot compensate from the neutral middle position. It sags down due to its weight and gravity.
AGM deflected with spring or air cartridge – gripper closed
Thanks to the weight compensation, the AGM can compensate for the existing axis offset between the gripper axis and the workpiece axis from the neutral center position in the x- and y-directions.
Combined units AGM-XYZ and AGM-WZ
The AGM-XYZ and AGM-WZ compensation units from SCHUNK combine several compensation paths in one compact component.
Both units are pre-assembled and available with their own ID as a standard solution. Thanks to the compact design of the combined units, you benefit from significant savings in structural height and inherent weight compared to individual, stacked compensation units. This saves space, reduces the load on the robot and end effector, and ensures efficient implementation of your processes.
Application example

Application example
During automated loading and unloading of machine tools, compensation units can effectively compensate for tolerances.
- 1
-
Combined compensation unit XYZ with optional spring cartridges
- 2
-
Universal gripper EGU