EGU
The robust powerhouse
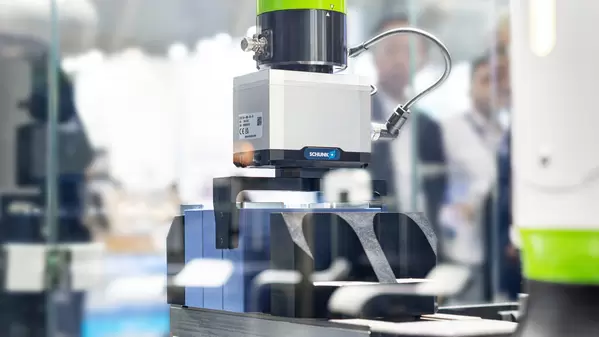
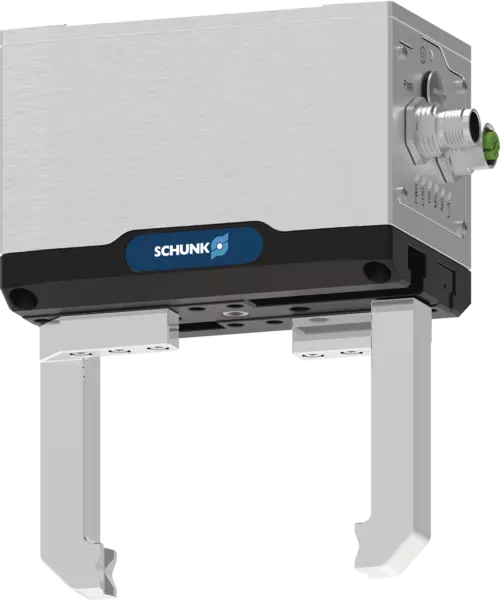
The electric universal gripper EGU is designed for demanding industrial environments and ensures reliable workpiece handling in daily production operations.
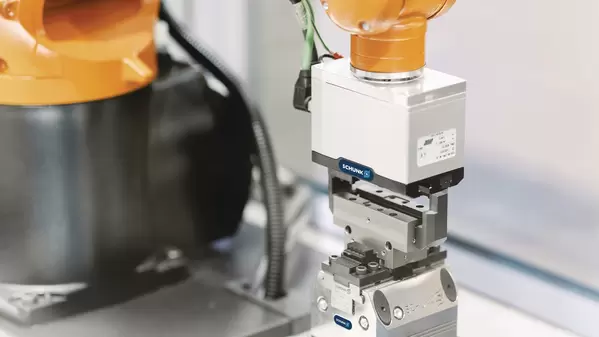
EGU in use
What makes the EGU special
Jedno chapadlo pro širokou škálu obrobků
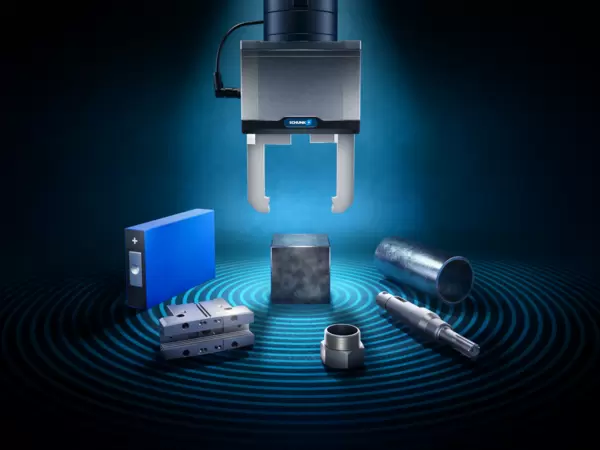
V průběhu výroby se obrobky, požadavky a velikosti sérií pravidelně mění. EGU se flexibilně přizpůsobuje různým komponentům a umožňuje manipulaci s širokou škálou variant dílů pomocí jediného chapadla. Zde je návod, jak můžete zkrátit dobu nastavování a udržet flexibilitu výroby.
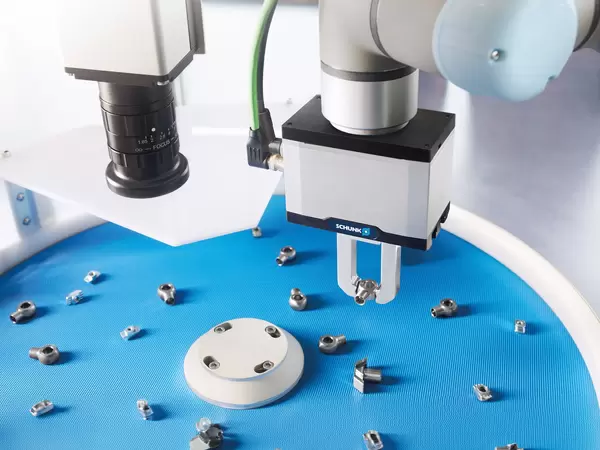
Začněte rychle a jednoduše
Od integrace až po uvedení do provozu: EGU lze rychle integrovat do stávajících automatizačních řešení. Standardizovaná rozhraní, robotické pluginy a předkonfigurované funkční bloky snižují náročnost integrace a urychlují zahájení projektu.
Vysoká procesní spolehlivost v provozu
V každodenním průmyslovém provozu hrají klíčovou roli spolehlivost a dostupnost. Díky udržení upínací síly, detekci ztráty obrobku a robustním vodicím lištám je zajištěna bezpečná manipulace s obrobky i v náročných podmínkách.
The benefits at a glance.
- Reliably handle workpieces even under demanding industrial conditions due to their robust design, which can withstand dust, coolant, and heavy loads.
- Handle a wide variety of workpieces using just one gripper, due to the large stroke range and continuously adjustable gripping force.
- Get started quickly and easily with a wide range of communication interfaces and comprehensive support, including robot plugins, PLC modules, open-source components, models for virtual commissioning, and the commissioning app in the SCHUNK Control Center.
- High process reliability even under high forces and torques, due to the heavy-duty T-slot sliding guide as well as integrated gripping force maintenance and workpiece loss detection.
- Systematically avoid interfering contours and speed up gripping processes by the parallel approach to a freely selectable pre-position even while the machine is still in motion.
- Continue working immediately after a restart, without the need for a reference run, due to a high-resolution absolute encoder.
- Grip and re-grip workpieces even in the event of positional deviations and tolerances without requiring additional approach travel through autonomous centering and controlled build-up of the gripping force via the drive.
- Control and monitor the gripping process precisely using customizable motion and handling functions, as well as status, error and warning messages.
- Virtually maintenance-free due to the use of brushless flat motors.