EZU
The powerful expert in centering.
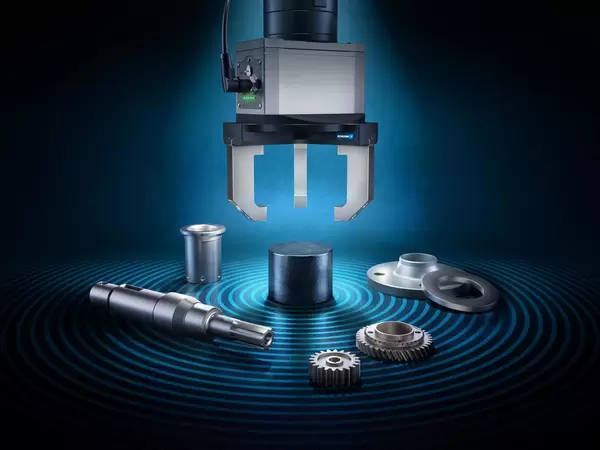
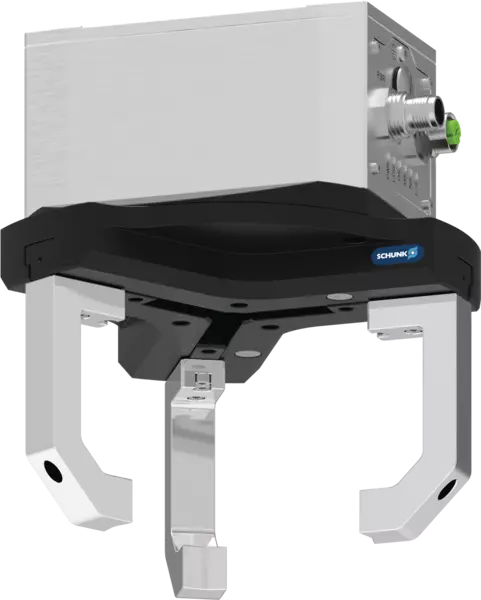
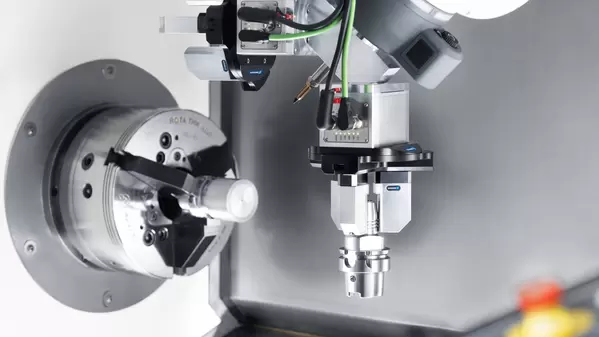
The EZU electric centric gripper was developed for challenging handling tasks. Due to its high gripping forces and robust design, it can reliably handle workpieces even under demanding production conditions and under heavy loads.
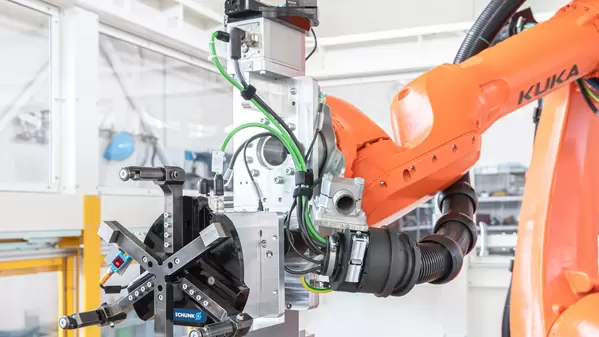
EZU in action
What makes the EZU special
One gripper for a wide variety of workpieces
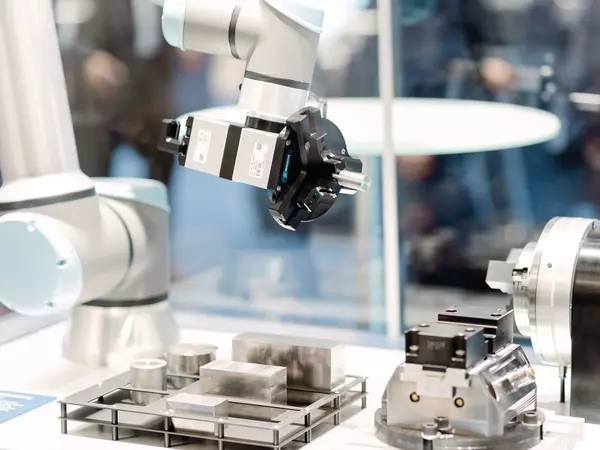
Large and heavy workpieces often present a variety of challenges when it comes to handling. Gripping force and stroke can be flexibly adjusted, allowing a single gripper to handle a variety of workpieces. This reduces the effort required for changeovers and simplifies automated processes.
Get started quickly and straightforwardly
The EZU is integrated using standardized communication interfaces, robotics plugins, and preconfigured function blocks. This makes it possible to implement new applications quickly and expand existing systems easily.
High process reliability in operation
When handling large and heavy workpieces, reliability is crucial. Gripping force maintenance, workpiece loss detection, and robust guides ensure that workpieces can be securely gripped and moved even under high loads.
The benefits at a glance.
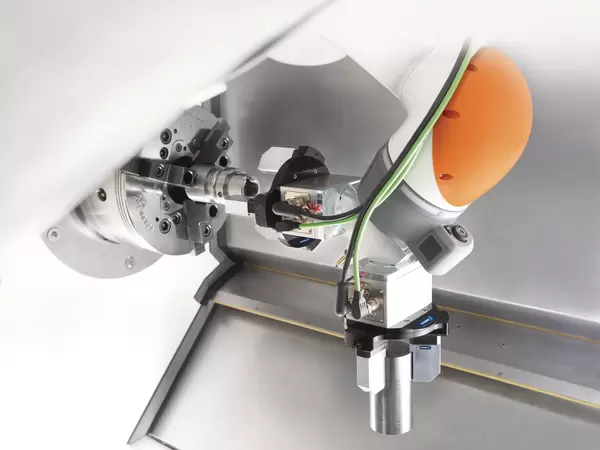
- Reliably handle workpieces even under demanding industrial conditions due to their robust design, which can withstand dust, coolant and heavy loads.
- Handle a wide variety of workpieces using just one gripper, due to the large stroke range and continuously adjustable gripping force.
- Get started quickly and easily with a wide range of communication interfaces and comprehensive support, including robot plugins, PLC modules, open-source components, models for virtual commissioning, and the commissioning app in the SCHUNK Control Center.
- High process reliability even under high forces and torques, due to the heavy-duty T-slot sliding guide as well as integrated gripping force maintenance and workpiece loss detection.
- Systematically avoid interfering contours and speed up gripping processes by the parallel approach to a freely selectable pre-position even while the machine is still in motion.
- Continue working immediately after a restart, without the need for a reference run, due to a high-resolution absolute encoder.
- Grip and re-grip workpieces even in the event of positional deviations and tolerances without requiring additional approach travel through autonomous centering and controlled build-up of the gripping force via the drive.
- Control and monitor the gripping process precisely using customizable motion and handling functions, as well as status, error and warning messages.
- Virtually maintenance-free due to the use of brushless flat motors.