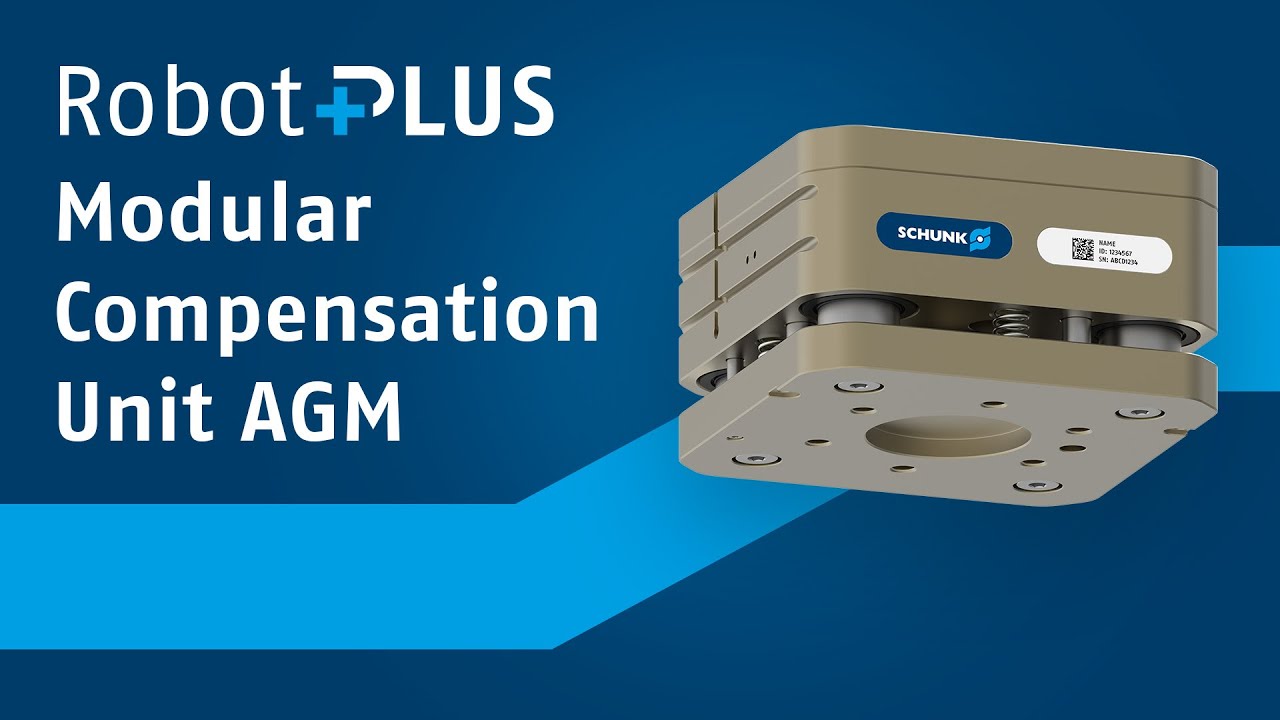

AGM-W
Function
断面図

断面図
AGM-W は、X軸とY軸の角度補正が可能です。特許取得済みの角度キネマティクスにより、異なる配置のワークに適応し、確実に把持することができます。ロッキングピストンは、ユニットのセンターロックを確実にし、所定の位置に固定します。一方、制御ピストンは、さまざまな空間位置での重量補正に使用することができます。
モジュール式でコンパクトな設計のため、他のAGMユニットとの組み合わせが可能です。ロック位置およびロック解除位置は、マグネットスイッチまたは近接センサーによって監視されます。
- 1
-
ISO mounting pattern
on the robot and tool side, for easy mounting on most types of robots without needing an additional adapter plate - 2
-
Locking piston
made of high-strength aluminum for pneumatically actuated, single-acting locking in a centric position. For moving during the process, we recommend applying pressure to the locking piston and the control piston. - 3
-
Control piston
made of hardened steel offers continuous adjustability of smooth running. For compensation in horizontal and inclined positions, we recommend actuation of the control piston for weight compensation. - 4
-
Patented angular kinematics
enables compensation in X and Y-axis - 5
-
Monitoring groove
for monitoring the locked position
Workpiece removal (vertical, hanging): AGM unlocked – gripper inactive

AGM unlocked – gripper active

AGM locked – gripper active

AGM locked – gripper active

For comparison: AGM-WZ angle compensation unlocked – gripper active

AGM unlocked – gripper active

AGM-XYZ と AGM-WZ を組み合わせたユニット

Workpiece removal (vertical, hanging): AGM unlocked – gripper inactive
The robot approaches the angled workpieces, which are arranged differently due to inaccuracies, with the gripper and the unlocked, combined compensation unit (AGM-WZ).
AGM unlocked – gripper active
The unlocked AGM-WZ can compensate for the different angles and heights of the workpieces, so the gripper can be positioned precisely on them and reliable removal is ensured.
AGM locked – gripper active
The robot picks up the workpiece and moves up.
AGM locked – gripper active
The robot moves to the deposit position with the gripped workpiece and the combined compensation unit (AGM-WZ). The Z-axis stroke of the Z unit is retracted and the angle unit is locked. This means that both the locking piston and the control piston (via air connections A and B) are pressurized with compressed air.
Due to tolerances or inaccuracies, there is an axis misalignment between the robot and the joining station.
For comparison: AGM-WZ angle compensation unlocked – gripper active
If the locking piston (A) and control piston (B) are not actuated, the AGM is not stabilized against its own weight and cannot perform angular compensation from the neutral middle position. It tilts downward due to its weight and gravity.
The Z-axis stroke of the Z unit remains retracted.
AGM unlocked – gripper active
To join the workpiece, depressurize the Z-unit and unlock the locking piston of the angle-unit (air connection A depressurized). Keep the control piston (B) of the angle unit pressurized with compressed air so that the unlocked AGM is held stable against gravity and does not tilt under its own weight.
AGM-XYZ と AGM-WZ を組み合わせたユニット
SCHUNK のAGM-XYZ および AGM-WZ の補正ユニットは、複数の補正経路を一つのコンパクトなコンポーネントに統合しています。
どちらのユニットもあらかじめ組み立ててあり、標準的なソリューションとして自身の ID で利用できます。コンパクトに設計された複合ユニットにより、個々の補正ユニットを積み重ねた場合と比べて、構造上の高さと自重を大幅に節約できます。これにより、スペースを節約し、ロボットやエンドエフェクターへの負荷を軽減し、プロセスの効率的な実行を保証します。
アプリケーション事例

アプリケーション事例
バラ積みピッキングの際には、角度補正のおかげで不正確さを補正することができ、これによってさまざまに配置されたコンポーネントを効果的に取り除くことができます。
- 1
-
補正ユニット AGM-W
- 2
-
磁気式グリッパー EMH