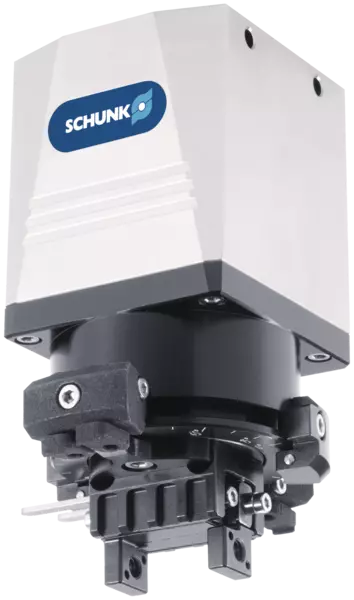
EGS 25-N-N-B
ID 310820
- 片側ストローク: 3 mm
- トルク: 0.04 Nm
Technical details
| 죠당 스트로크 [mm] | 3.0 |
|---|---|
| 최소 파지력 [N] | 15.0 |
| 최대 파지력 [N] | 30.0 |
| 정격 토크 [Nm] | 0.04 |
| 최소 회전 각도 [°] | 30 |
| 최대 회전 각도 [°] | 270 |
| 권고 공작물 중량 [kg] | 0.15 |
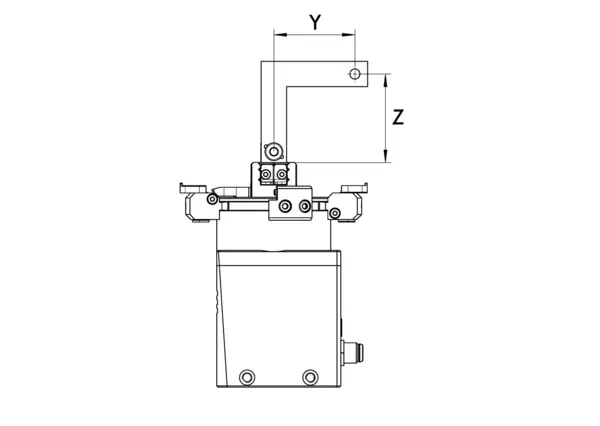
| 최대 허용 가능 핑거 길이 [mm] | 32.0 |
| 핑거당 최대 허용 무게 [kg] | 0.02 |
| 관성의 최대 허용 가능한 질량 모멘트 [kgmm²] | 50.0 |
| 그리핑을 위한 반복 정확도 [mm] | 0.02 |
| 선회를 위한 반복 정확도 [°] | ± 0.5 |
| 폐쇄 시간 [s] | 0.05 |
| 개방 시간 [s] | 0.05 |
| 중량 [kg] | 0.45 |
| 최소 주위 온도 [°C] | 5.0 |
| 최대 주위 온도 [°C] | 55.0 |
| IP 보호등급 | 30 |
| 소음 방출 [dB(A)] | < 70 |
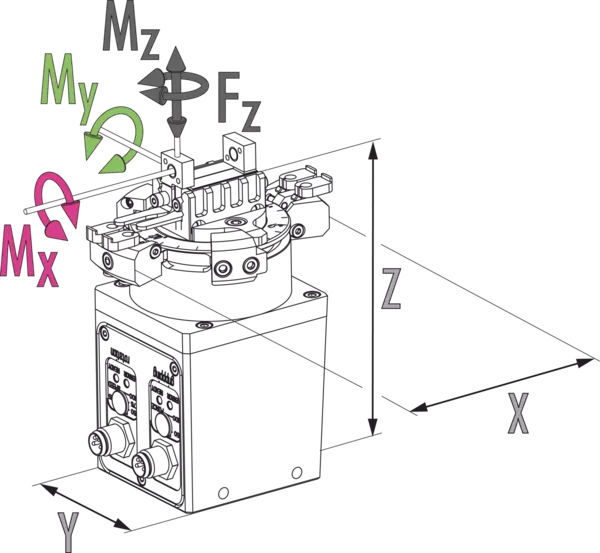
| 길이 X [mm] | 69.8 |
| 너비 Y [mm] | 45.0 |
| 높이 Z [mm] | 88.8 |
| 컨트롤러 전자 장치 | 통합형 |
| 정격 전압 [V] | 24.0 |
| 정격 전류 [A] | 0.8 |
| 최대 전류 [A] | 1.2 |
| 통신 인터페이스 | 디지털 I/O |
| 디지털 입력 수 | 4.0 |
| 모멘트 Mx 최대 [Nm] | 0.5 |
| 모멘트 My 최대 [Nm] | 0.42 |
| 모멘트 Mz 최대 [Nm] | 1.5 |
| 포스 Fz 최대 [N] | 70.0 |
Dimensions and maximum loads
Maximum permitted finger projection
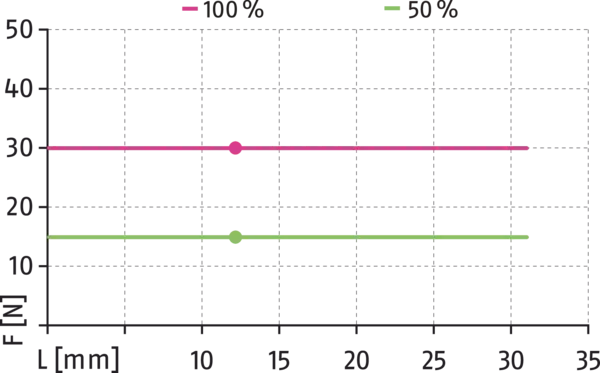
파지력
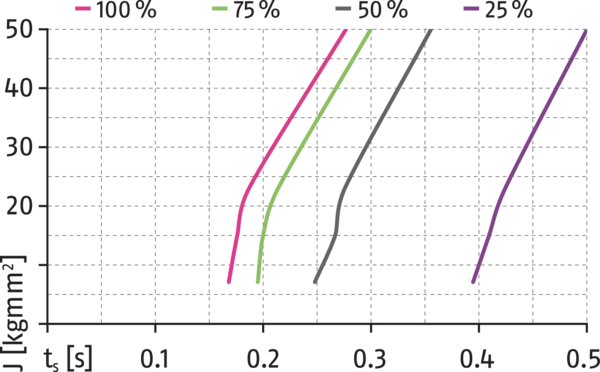
스위블 시간* 180°
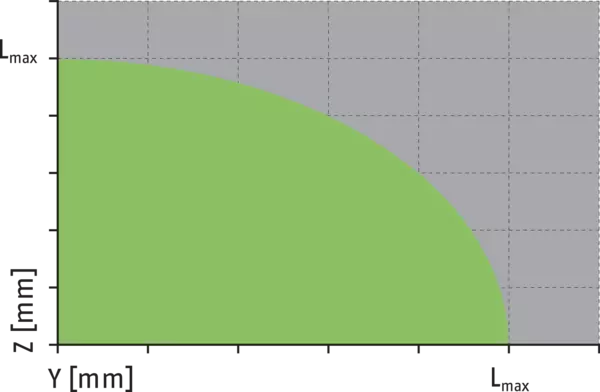
최대 허용 핑거 추정
Dimensions and maximum loads
The indicated moments and forces are statical values, apply for each base jaw and may appear simultaneously. Loads may additionally occur to the moment produced by the gripping force itself.
Maximum permitted finger projection
파지력
- X-axis:
- 핑거 길이
- Y-axis:
- 파지력
스위블 시간* 180°
- X-axis:
- 선회 시간
- Y-axis:
- 관성의 질량 모멘트
- X-axis top:
- 시간당 사이클
최대 허용 핑거 추정
Lmax는 최대치의 허용 핑거 길이에 해당합니다. 기술 데이터 표를 참조하십시오.
- green
- Permitted range
- grey
- Inadmissible range
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy
is defined as a distribution of the end Position for 100 consecutive strokes.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing, opening and swiveling times
are pure movement times of the module. PLC reaction times are not included and have to be considered when the cycle times are determined.
Operating principle
Rack and pinion principle
Housing material
Aluminum alloy, coated
Base jaw material
Steel
Actuation
servo-electric, via brushless DC servomotors
Warranty
24 months
Service life characteristics
on request
Scope of delivery
Gripper including safety information and accessory kit with centering sleeves for gripper and finger mounting. Product-specific instructions and software can be downloaded at schunk.com/downloads-manuals and schunk.com/downloads-software.