

EZN 100
ID 306112
代替製品:
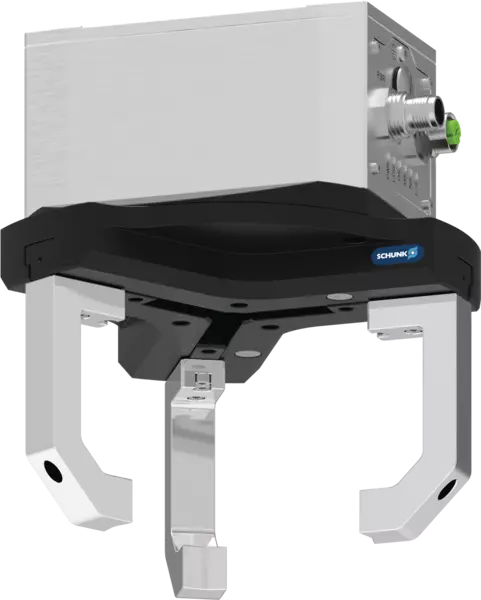
- Stroke per jaw: 10 mm
- Min. gripping force: 300 N
- Max. gripping force: 800 N
- Power supply: 24 V
- Max. total current: 4 A
- Max. ambient temperature: 55 °C
技術的詳細
| 片側ストローク [mm] | 10.0 |
|---|---|
| 最小把持力 [N] | 300.0 |
| 最大把持力 [N] | 800.0 |
| 推奨ワーク重量 [kg] | 4.0 |
| 最大許容フィンガー長 [mm] | 125.0 |
| 最大許容重量/フィンガー [kg] | 1.1 |
| 繰り返し精度 [mm] | ± 0.01 |
| 最小エアパージ圧力 [bar] | 0.5 |
| 最大エアパージ圧力 [bar] | 1.0 |
| 閉時間 [s] | 0.4 |
| 開時間 [s] | 0.4 |
| 最大速度 [mm/s] | 80.0 |
| 最大加速度 [mm/s²] | 1500.0 |
| 重量 [kg] | 2.3 |
| 最低周囲温度 [°C] | 5.0 |
| 最高周囲温度 [°C] | 55.0 |
| IP 保護等級 | 41 |
| D 径 [mm] | 110.5 |
| 高さ Z [mm] | 147.5 |
| 定格電流 [A] | 2.2 |
| 最大電流 [A] | 4.0 |
| 電子コントローラー | 外付け |
| コントローラータイプ | ECM-EZN100 |
| 通信インターフェース | コントローラー ECM を参照 |
| モーメント Mx 最大 [Nm] | 80.0 |
| トルク My 最大 [Nm] | 115.0 |
| モーメント Mz最大 [Nm] | 70.0 |
| 最大軸方向力 Fz (最大) [N] | 2000.0 |
Dimensions and maximum loads

把持力

Speed

Dimensions and maximum loads
The indicated moments and forces are statical values, apply for each base jaw and may appear simultaneously. Loads may additionally occur to the moment produced by the gripping force itself.
把持力
- X 軸:
- ポイント P - フィンガー長
- Y 軸:
- 把持力
Speed
- X 軸:
- Stroke
- Y 軸:
- Speed
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy
is defined as a distribution of the end Position for 100 consecutive strokes.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing and opening times
Minimum closing and opening times are merely the movement times of the base jaws or fingers at max. speed, max. acceleration, without current limitation (maximum current), and observance of the maximum permissible mass per finger.
Nominal currents
can be permanently actuated. With regard to all the currents which are ranging above the nominal current up to the maximum current, the notes of the individual product documentation has to be respected.
Operating principle
Wedge-hook kinematics
Housing material
Aluminum alloy, coated
Base jaw material
Steel
Actuation
servo-electric, via brushless DC servomotor and spindle drive
Warranty
24 months
Service life characteristics
on request
Scope of delivery
Gripper including safety information and accessory kit with centering sleeves for gripper and finger mounting. Product-specific instructions and software can be downloaded at schunk.com/downloads-manuals and schunk.com/downloads-software.