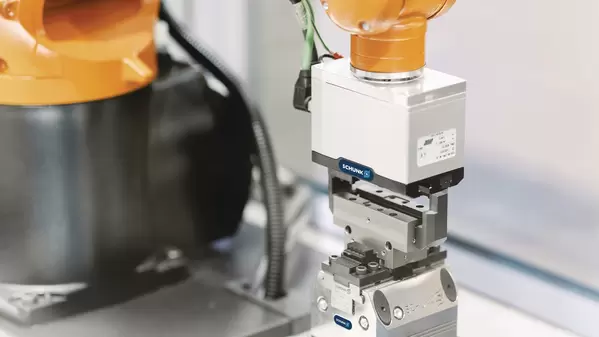
EGU
The robust powerhouse
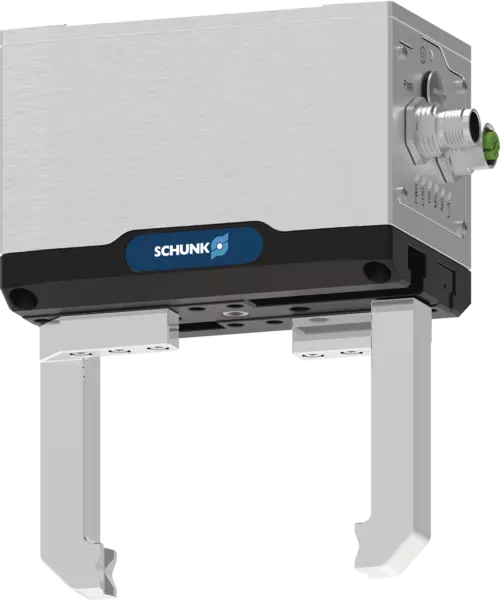
The electric universal gripper EGU is designed for demanding industrial environments and ensures reliable workpiece handling in daily production operations.
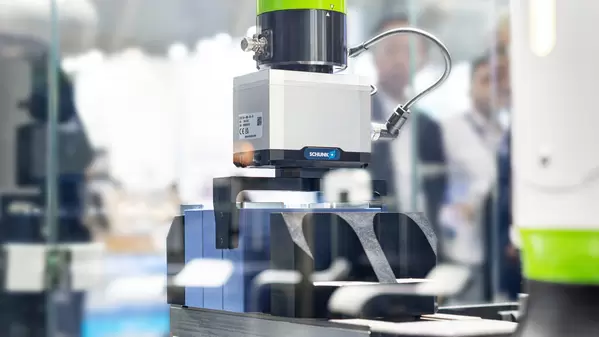
EGU in use
What makes the EGU special
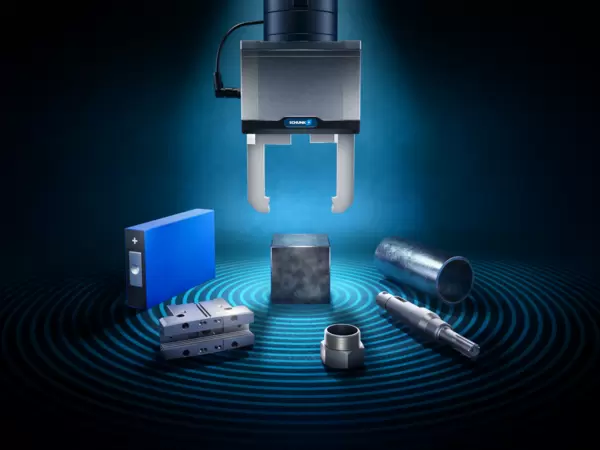
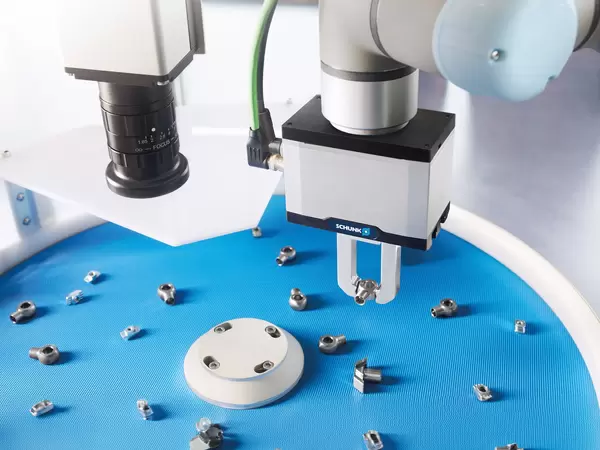
One gripper for a wide variety of workpieces
During production, workpieces, requirements, and batch sizes change regularly. The EGU adapts flexibly to different components and allows a wide variety of part variants to be handled with just one gripper. Here is how you can reduce setup time and keep your production flexible.
Get started quickly and straightforwardly
From integration to commissioning: The EGU can be quickly integrated into existing automation solutions. Standardized interfaces, robot plugins, and preconfigured function blocks reduce the effort required for integration, and speed up project startup.
High process reliability in operation
In everyday industrial operations, reliability and availability are key. Gripping force maintenance, workpiece loss detection, and robust guides ensure that workpieces can be handled safely even under demanding conditions.
The benefits at a glance.
- Reliably handle workpieces even under demanding industrial conditions due to their robust design, which can withstand dust, coolant, and heavy loads.
- Handle a wide variety of workpieces using just one gripper, due to the large stroke range and continuously adjustable gripping force.
- Get started quickly and easily with a wide range of communication interfaces and comprehensive support, including robot plugins, PLC modules, open-source components, models for virtual commissioning, and the commissioning app in the SCHUNK Control Center.
- High process reliability even under high forces and torques, due to the heavy-duty T-slot sliding guide as well as integrated gripping force maintenance and workpiece loss detection.
- Systematically avoid interfering contours and speed up gripping processes by the parallel approach to a freely selectable pre-position even while the machine is still in motion.
- Continue working immediately after a restart, without the need for a reference run, due to a high-resolution absolute encoder.
- Grip and re-grip workpieces even in the event of positional deviations and tolerances without requiring additional approach travel through autonomous centering and controlled build-up of the gripping force via the drive.
- Control and monitor the gripping process precisely using customizable motion and handling functions, as well as status, error and warning messages.
- Virtually maintenance-free due to the use of brushless flat motors.