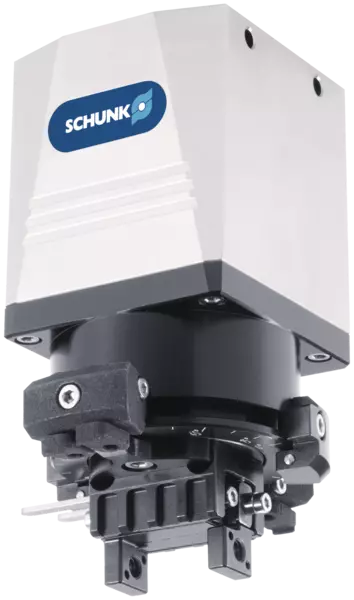
EGS 25-N-N-B
ID 310820
- Course par mors : 3 mm
- Couple: 0.04 Nm
Technical details
| Course par mors [mm] | 3.0 |
|---|---|
| Force de préhension min. [N] | 15.0 |
| Force de préhension max. [N] | 30.0 |
| Couple nominal [Nm] | 0.04 |
| Angle de rotation min. [°] | 30 |
| Angle de rotation max. [°] | 270 |
| Poids de pièce recommandé [kg] | 0.15 |
| Longueur de doigt max. admissible [mm] | 32.0 |
| Poids de doigt max. admissible [kg] | 0.02 |
| moment d'inertie de masse maximum admissible [kgmm²] | 50.0 |
| Répétabilité en la préhension [mm] | 0.02 |
| Répétabilité en la rotation [°] | ± 0.5 |
| Temps de fermeture [s] | 0.05 |
| Temps d'ouverture [s] | 0.05 |
| Poids [kg] | 0.45 |
| Température ambiante mini. [°C] | 5.0 |
| Température ambiant maxi. [°C] | 55.0 |
| Indice de protection IP | 30 |
| Emission de bruit [dB(A)] | < 70 |
| Longueur X [mm] | 69.8 |
| Largeur Y [mm] | 45.0 |
| Hauteur Z [mm] | 88.8 |
| Electronique de commande | intégré(e) |
| Tension nominale [V] | 24.0 |
| Courant nominal [A] | 0.8 |
| Courant max. [A] | 1.2 |
| Interface de communication | E/S numériques |
| Nombre d'entrées digitales | 4.0 |
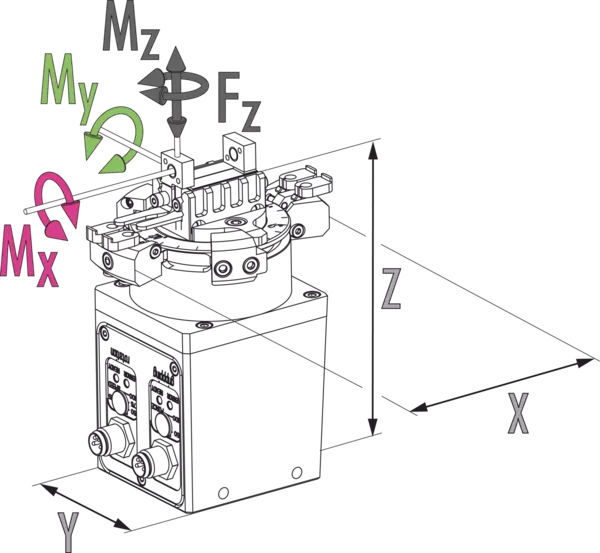
| Moment Mx max. [Nm] | 0.5 |
| Moment My max. [Nm] | 0.42 |
| Moment Mz max. [Nm] | 1.5 |
| Force Fz max. [N] | 70.0 |
Dimensions et charges max.
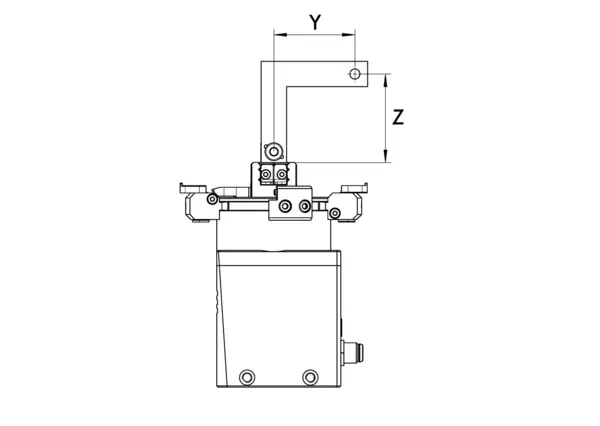
Dépassement maximum autorisé
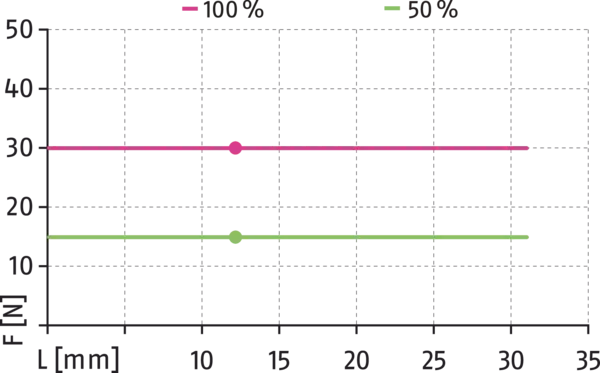
Force de préhension
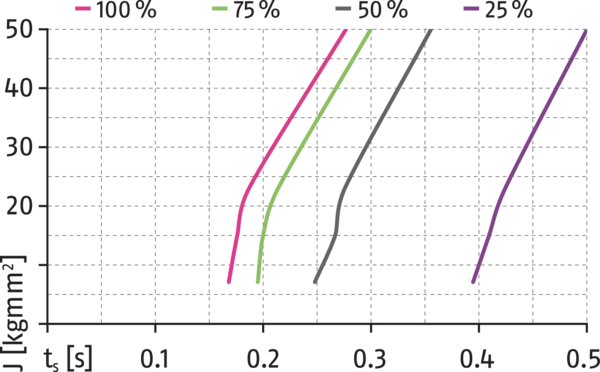
Temps de pivotement* 180°
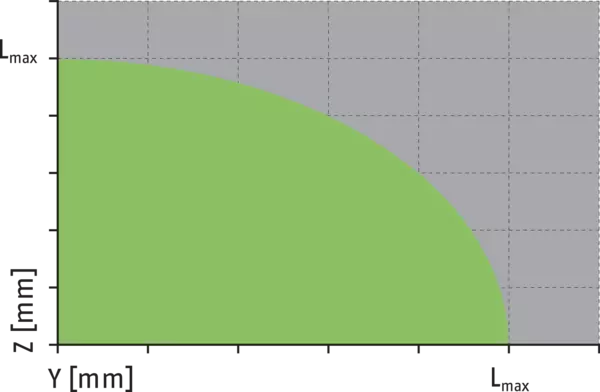
Dépassement maximum autorisé
Dimensions et charges max.
Les moments et les forces indiqués correspondent à des valeurs statiques et s'appliquent à chacun des mors de base et peuvent survenir simultanément. Ils peuvent s’ajouter au moment produit par la force de préhension elle-même.
Dépassement maximum autorisé
Force de préhension
- X-axis:
- Longueur des doigts
- Y-axis:
- Force de préhension
Temps de pivotement* 180°
- X-axis:
- Temps de rotation
- Y-axis:
- Moment d'inertie de masse
- X-axis top:
- Cycles par heure
Dépassement maximum autorisé
Lmax correspond à la longueur de doigt maximale admissible, voir tableau des caractéristiques techniques.
- green
- Plage admissible
- grey
- Plage non admissible
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy
is defined as a distribution of the end Position for 100 consecutive strokes.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing, opening and swiveling times
are pure movement times of the module. PLC reaction times are not included and have to be considered when the cycle times are determined.
Operating principle
Rack and pinion principle
Housing material
Aluminum alloy, coated
Base jaw material
Steel
Actuation
servo-electric, via brushless DC servomotors
Warranty
24 months
Service life characteristics
on request
Scope of delivery
Gripper including safety information and accessory kit with centering sleeves for gripper and finger mounting. Product-specific instructions and software can be downloaded at schunk.com/downloads-manuals and schunk.com/downloads-software.