
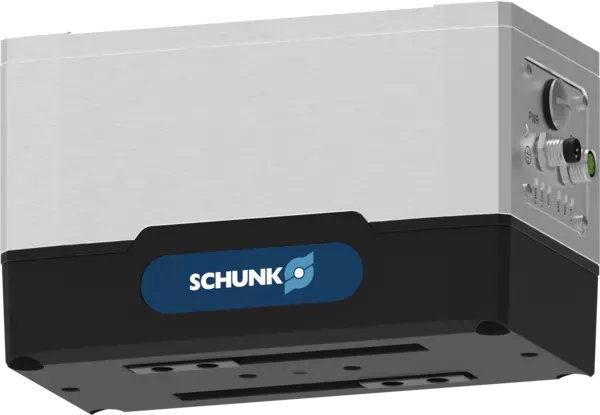
EGK 50-MB-N-B
ID 1491775
- Stroke per jaw: 51.5 mm
- Min. gripping force: 150 N
- Max. gripping force: 300 N
- Power supply: 24 V
- Max. ambient temperature: 55 °C
Technical details
| Zdvih na čelist [mm] | 51.5 |
|---|---|
| Min. uchopovací síla [N] | 150.0 |
| Max. uchopovací síla [N] | 300.0 |
| Max. přípustná délka prstu [mm] | 130.0 |
| Max. přípustná hmotnost jednoho prstu [kg] | 0.5 |
| Přesnost polohování [mm] | ± 0.3 |
| Opakovatelná přesnost (uchopování) [mm] | 0.03 |
| Opakovatelná přesnost (polohování, všesměrové) [mm] | 0.1 |
| Opakovatelná přesnost (polohování, obousměrné) [mm] | 0.2 |
| Doba zavření [s] | 0.54 |
| Doba otevření [s] | 0.54 |
| Max. rychlost (polohování) [mm/s] | 130.0 |
| Max. zrychlení [mm/s²] | 1000.0 |
| Vlastní hmotnost [kg] | 1.59 |
| Min. okolní teplota [°C] | 5.0 |
| Max. okolní teplota [°C] | 55.0 |
| Třída ochrany IP, elektronika | 67 |
| Třída krytí IP, vedení/základní čelisti | 20 |
| Čistota místnosti třída ISO 14644-1 | 5 |
| Stav certifikace Třída čistého prostoru ISO 14644-1 | 2015 |
| Délka X [mm] | 147.0 |
| Šířka Y [mm] | 78.0 |
| Výška Z [mm] | 90.0 |
| Jmenovité napětí [V] | 24.0 |
| Komunikační rozhraní | Modbus RTU |
| Jmenovitý příkon, výkon [A] | 0.22 |
| Spotřeba energie maximální výkon [A] | 0.82 |
| Logická jmenovitá spotřeba proudu. [A] | 0.16 |
| Logická maximální spotřeba proudu. [A] | 0.2 |
| Max. moment Mx [Nm] | 9.0 |
| Max. moment My [Nm] | 9.0 |
| Max. moment Mz [Nm] | 5.0 |
| Max. axiální síla Fz max. [N] | 700.0 |
| Verze bez udržování uchopovací síly | ano |
寸法と最大荷重

Maximum permitted finger projection

Režimy uchopení

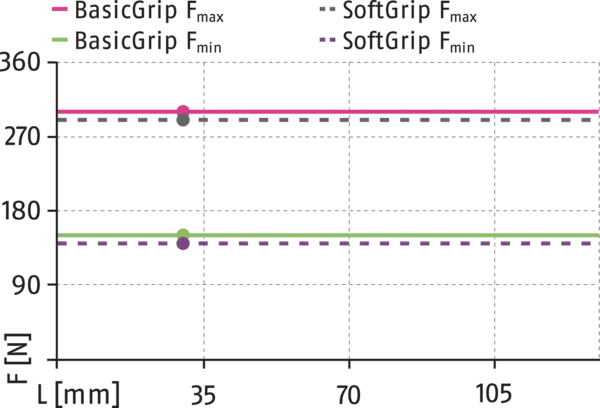
把持力
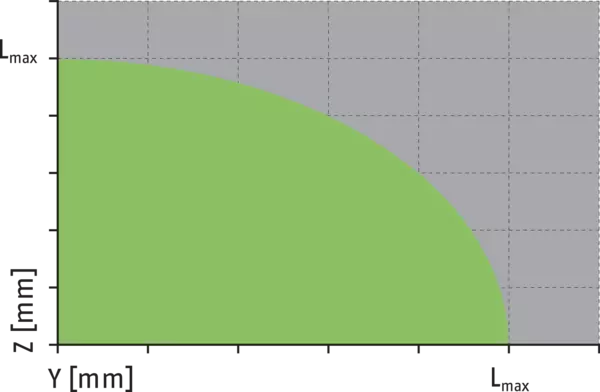
最大許容フィンガー突起
寸法と最大荷重
示されたモーメントと荷重は固定値であり、各ベースジョーに作用し、同時発生することがあります。また、荷重は、把持力自体によって生成されたモーメントと別に発生することがあります。
Maximum permitted finger projection
Režimy uchopení
- X-axis:
- Provozní doba
- Y-axis:
- Uchopovací síla
把持力
- X-axis:
- フィンガー長
- Y-axis:
- 把持力
最大許容フィンガー突起
Lmax は、最大許容フィンガー長に該当します。テクニカルデータ表をご参照ください。
- green
- 許容範囲
- grey
- 許容不可範囲
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Repeat accuracy (gripping)
defined as the spread of the actual position per jaw during 100 consecutive closing or opening movements on a rigid workpiece or a fixed stop under constant conditions.
Repeat accuracy (positioning, unidirectional)
defined as the spread of the actual position per base jaw during 100 consecutive movements to a target position from the same direction under constant conditions.
Repeat accuracy (positioning, bi-directional)
defined as the distribution of the actual position per base jaw during 100 consecutive movements to a target position from both directions under constant conditions.
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Positioning accuracy
is defined as the deviation of the actual position per jaw during 100 consecutive, unidirectional positioning movements to a defined position under constant conditions.
Closing and opening times (positioning)
Closing and opening times are only the movement times of the fingers at max. speed, as well as max. acceleration with observance of the max. permissible mass per finger and refer to the traverse path per jaw and 50% of the nominal stroke.
Max. speed (positioning) and max. acceleration
is the arithmetic sum of the velocity and acceleration acting on each jaw.
Housing material
Aluminum alloy, anodized
Base jaw material
hard-anodized, high strength aluminum
Warranty
24 months or 5 million cycles (one cycle consists of a complete gripping process: "Open gripper" and "Close gripper")
Scope of delivery
Gripper including safety information and accessory kit with centering sleeves for gripper and finger mounting. Product-specific instructions and software can be downloaded at schunk.com/downloads-manuals and schunk.com/downloads-software.