arrow calendar cartcheck checkmark close configure contact danger download external_link facebook globeinfo instagram jobfinder linkedin logo_claim logout mail menuminus navigation pin play plus rss searchshaft success twitteruserwarning wechat x-twitterxing youku youtube zoom
更改地区选项,查看您所在区域可供应的产品、服务和联系人的相关信息。
EZU

EZU

定心机械手
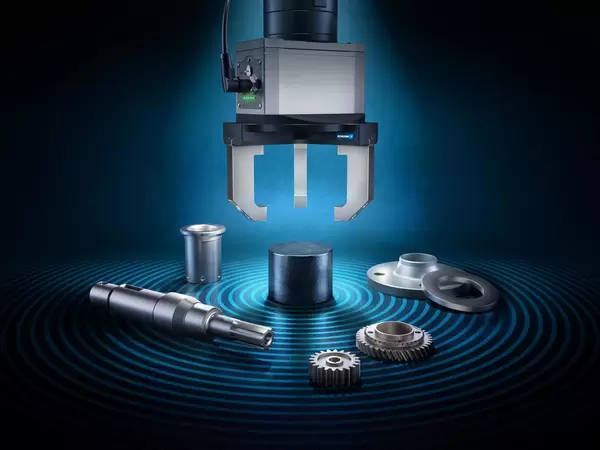
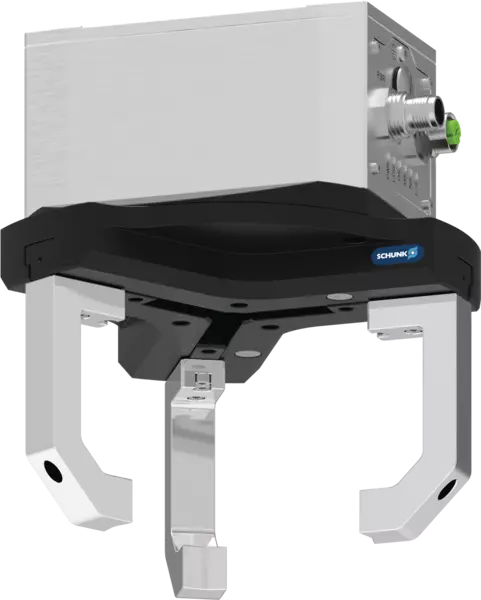
电动中心机械手,用于可靠搬运各种不同几何形状的工件。
SCHUNK - EZU

The powerful expert in centering.​

High forces. Reliable processes.​
Reliable handling for cylindrical workpieces.

The EZU electric centric gripper was developed for challenging handling tasks. Due to its high gripping forces and robust design, it can reliably handle workpieces even under demanding production conditions and under heavy loads.​

EZU in action​

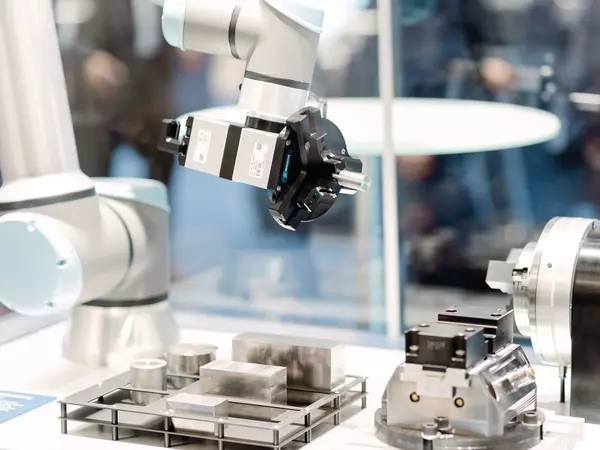
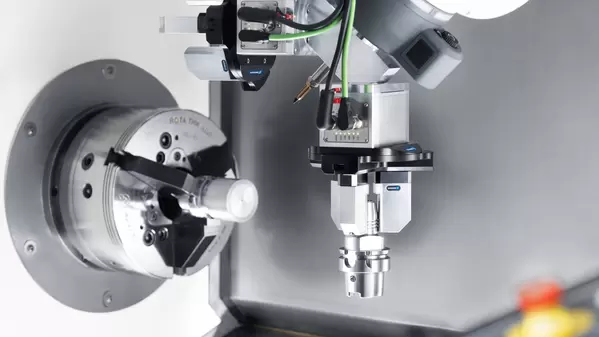
기계 로딩

자동화된 로딩 및 언로딩 공정을 위한 무거운 공작물의 안정적인 핸들링.​

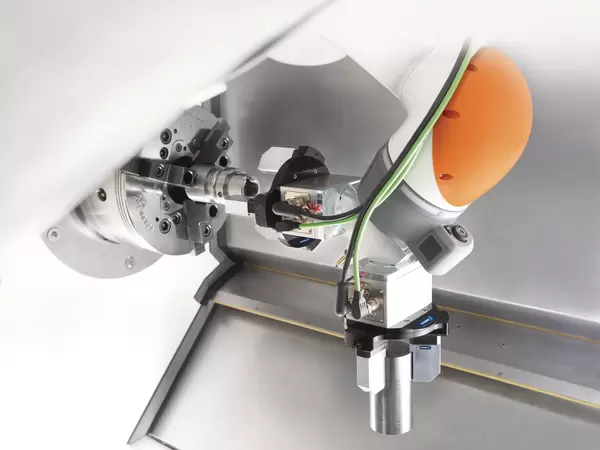
금속 가공​

칩과 냉각수가 있거나 환경 조건이 까다로운 곳에서도 견고한 공작물 핸들링.​

What makes the EZU special​

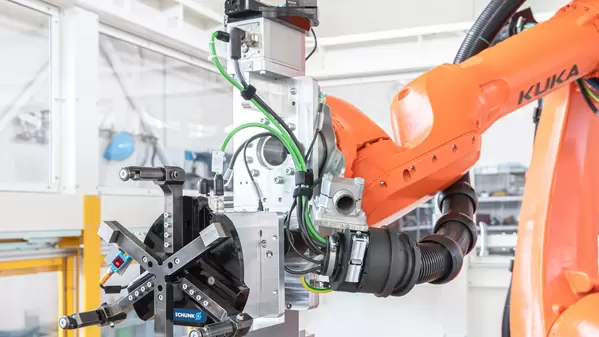
그리퍼 하나로 다양한 공작물에 대응

크고 무거운 공작물은 핸들링 시 여러 가지 어려움이 따르는 경우가 많습니다. EZU는 파지력과 스트로크를 유연하게 조정할 수 있어 그리퍼 하나로 다양한 공작물을 핸들링할 수 있습니다. 이를 통해 품종 전환에 드는 수고를 줄이고 자동화 공정을 간소화할 수 있습니다.​

内容即将推出

빠르고 간편하게 시작

EZU는 표준화된 통신 인터페이스, 로봇 플러그인, 사전 구성된 기능 블록을 통해 통합됩니다. 따라서 새로운 애플리케이션을 빠르게 구현하고 기존 시스템을 손쉽게 확장할 수 있습니다.​

운용 중에도 높은 공정 신뢰성

크고 무거운 공작물을 핸들링할 때는 신뢰성이 무엇보다 중요합니다. 파지력 유지, 공작물 이탈 감지 기능과 견고한 가이드 덕분에 높은 하중에서도 공작물을 확실하게 파지하고 이동할 수 있습니다.​

内容即将推出

The benefits at a glance.

  • Reliably handle workpieces even under demanding industrial conditions due to their robust design, which can withstand dust, coolant and heavy loads.​
  • Handle a wide variety of workpieces using just one gripper, due to the large stroke range and continuously adjustable gripping force.​
  • Get started quickly and easily with a wide range of communication interfaces and comprehensive support, including robot plugins, PLC modules, open-source components, models for virtual commissioning, and the commissioning app in the SCHUNK Control Center.​
  • High process reliability even under high forces and torques, due to the heavy-duty T-slot sliding guide as well as integrated gripping force maintenance and workpiece loss detection.​
  • Systematically avoid interfering contours and speed up gripping processes by the parallel approach to a freely selectable pre-position even while the machine is still in motion​.
  • Continue working immediately after a restart, without the need for a reference run, due to a high-resolution absolute encoder.​
  • Grip and re-grip workpieces even in the event of positional deviations and tolerances without requiring additional approach travel through autonomous centering and controlled build-up of the gripping force via the drive.​
  • Control and monitor the gripping process precisely using customizable motion and handling functions, as well as status, error and warning messages.​
  • Virtually maintenance-free due to the use of brushless flat motors.​