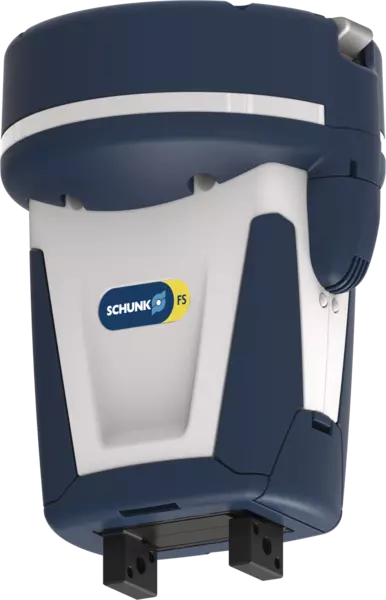
Co-act EGP-C 40-N-N-KTOE
Collaborating gripper for small components
ID 1321170
This product has been discontinued and is no longer available.
Learn more and get in touch here.
Collaborating gripper for small components Co-act EGP-C, Size: 40, electrical, Compatible robot: KUKA LBR iiwa 7/14, Robot flange: Media flange touch electric, Communication interface: digital I/O
- Stroke per jaw: 6 mm
- Min. gripping force: 35 N
- Max. gripping force: 140 N
- Power supply: 24 V
- Max. total current: 2 A
- Max. ambient temperature: 55 °C
Technical details
| Compatible robot | KUKA LBR iiwa 7/14 |
|---|---|
| Robot flange | Media flange touch electric |
| LED strip light | integrated |
| Displayable colors | green, yellow, red |
| Integrated sensors | yes, inductive in two directions |
| Length X [mm] | 93.8 |
| Width Y [mm] | 90.2 |
| Height Z [mm] | 123.0 |
| Stroke per jaw [mm] | 6.0 |
| Min. gripping force [N] | 35.0 |
| Max. gripping force [N] | 140.0 |
| Min. force per jaw [N] | 17.5 |
| Max. force per jaw [N] | 70.0 |
| Recommended workpiece weight [kg] | 0.7 |
| Max. permissible finger length [mm] | 50.0 |
| Max. permissible weight per finger [kg] | 0.08 |
| Repeat accuracy [mm] | 0.02 |
| Closing time [s] | 0.2 |
| Opening time [s] | 0.2 |
| Weight [kg] | 0.62 |
| Min. ambient temperature [°C] | 5.0 |
| Max. ambient temperature [°C] | 55.0 |
| IP protection class | 30 |
| Cable connector/cable end | M12 |
| Cable length [mm] | 70.0 |
| Nominal voltage [V] | 24.0 |
| Nominal current [A] | 0.2 |
| Max. current [A] | 2.0 |
| Controller electronics | integrated |
| Communication interface | digital I/O |
| Number of digital inputs | 4.0 |
| Number of digital outputs | 2.0 |
| Moment Mx max. [Nm] | 1.5 |
| Moment My max. [Nm] | 2.0 |
| Moment Mz max. [Nm] | 4.0 |
| Max. axial force Fz max. [N] | 170.0 |
尺寸和最大载荷
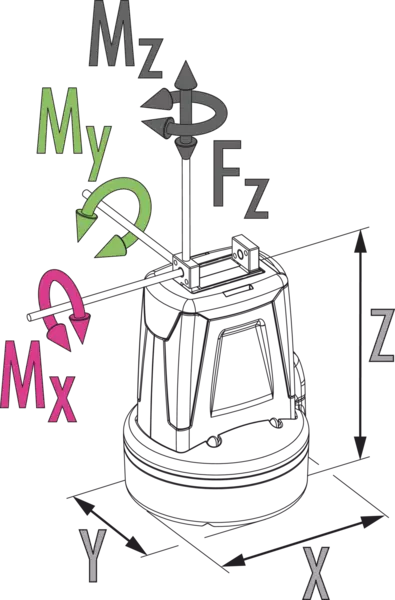
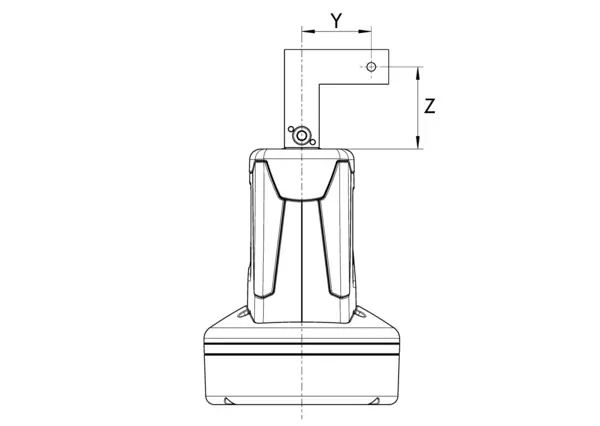
最大允许手指投影
Gripping force
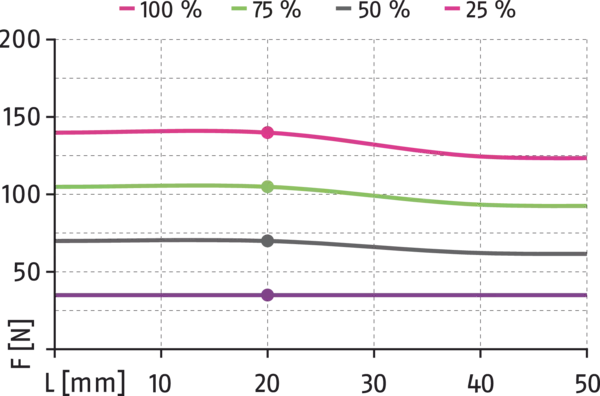
最大允许手指投影
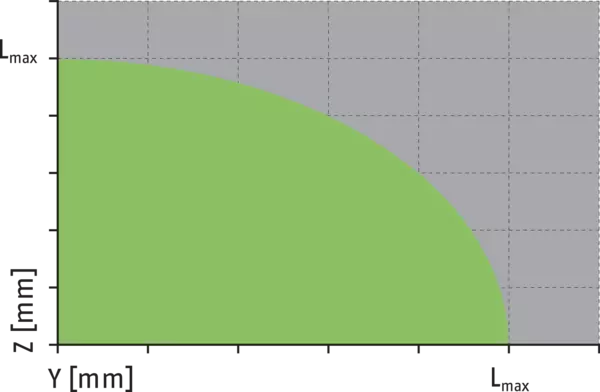
尺寸和最大载荷
所示力矩和力为静态值,适用于每个基爪,且可能会同时出现。除抓取力自身产生的力矩外,还可能产生负载。
最大允许手指投影
Gripping force
- X-axis:
- 手指长度
- Y-axis:
- 抓取力
最大允许手指投影
Lmax 等于最大允许手指长度。请参见技术参数表。
- green
- 允许的范围
- grey
- 不允许的范围
产品系列的常规说明
抓取力
在距离 P(请参见插图)处施加到每个机械手夹爪的抓取力的算术和。了解更多信息,请参阅详细的功能说明。
手指长度
沿主轴方向,从距基准面距离 P 处测得。
重复精度
定义为 100 个连续行程后极限位置分布。
工件重量
采用摩擦系数 0.1 和安全系数(防止由于重力加速 g 工件滑落) 2 计算压入配合抓取。如果是适形或捕获式抓取,可抓取工件重量则大很多。 了解更多信息,请参阅装配和操作手册。
闭合/打开时间
仅是基爪的移动时间,不包含特定应用的机械手手指。上述时间不包括 PLC 反应时间,但是确定周期时必须考虑。
工作原理
齿条和齿轮传动原理
外壳材料
添加玻璃纤维的聚酰胺
基爪材料
钢
启动
伺服电动,通过无刷直流伺服电机
保修期
参见装配和操作手册
使用寿命特性
根据要求
标配范围
配件包包含转接法兰、安装材料和六角套筒扳手,含符合性和组装声明、安全信息的装配和操作手册。