

EGI 040-EC
ID 1474383
Alternative products:
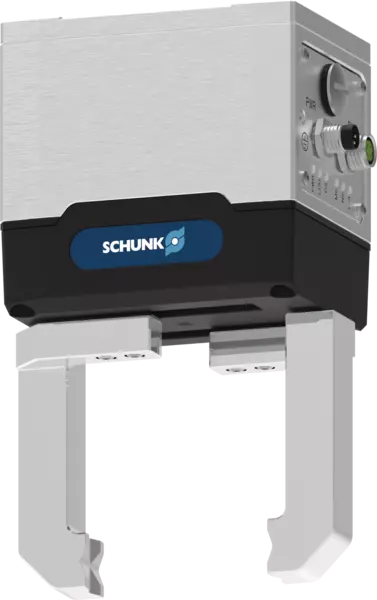
- Zdvih na čelist: 40 mm
- Min. uchopovací síla: 25 N
- Max. uchopovací síla: 70 N
- Napájení: 24 V
- Max. okolní teplota: 55 °C
Technical details
| Zdvih na čelist [mm] | 40.0 |
|---|---|
| Min. uchopovací síla [N] | 25.0 |
| Max. uchopovací síla [N] | 70.0 |
| Zařízení udržující upínací sílu i v případě výpadku médií | nedostupný |
| Doporučená hmotnost obrobku [kg] | 0.35 |
| Max. přípustná délka prstu [mm] | 150.0 |
| Max. přípustná hmotnost jednoho prstu [kg] | 0.2 |
| Opakovatelná přesnost (uchopování) [mm] | 0.03 |
| Opakovatelná přesnost (polohování, všesměrové) [mm] | 0.06 |
| Opakovatelná přesnost (polohování, obousměrné) [mm] | 0.3 |
| Doba zavření [s] | 1.0 |
| Doba otevření [s] | 1.0 |
| Typický čas cyklu [s] | 0.6 |
| Max. rychlost [mm/s] | 100.0 |
| Max. zrychlení [mm/s²] | 2000.0 |
| Vlastní hmotnost [kg] | 1.02 |
| Min. okolní teplota [°C] | 5.0 |
| Max. okolní teplota [°C] | 55.0 |
| Třída ochrany IP | 20 |
| Hlukové emise [dB(A)] | < 70 |
| Čistota místnosti třída ISO 14644-1 | 5 |
| Stav certifikace Třída čistého prostoru ISO 14644-1 | 2015 |
| Délka X [mm] | 135.0 |
| Šířka Y [mm] | 52.0 |
| Výška Z [mm] | 84.5 |
| Řídicí elektronika | integrované |
| Jmenovité napětí [V] | 24.0 |
| Komunikační rozhraní | EtherCAT |
| Max. výstupní výkon [A] | 0.7 |
| Max. logický proud [A] | 0.25 |
| Max. moment Mx [Nm] | 4.5 |
| Max. moment My [Nm] | 4.5 |
| Max. moment Mz [Nm] | 3.0 |
| Max. axiální síla Fz max. [N] | 140.0 |
Rozměry a maximální zatížení

Maximální přípustný přesah

Uchopovací síla

Maximální přípustný přesah

Rozměry a maximální zatížení
Uvedené točivé momenty a síly jsou statickými hodnotami platnými pro každou základní čelist a mohou vzniknout současně.
Maximální přípustný přesah
Uchopovací síla
- X-axis:
- Délka prstu
- Y-axis:
- Uchopovací síla
Maximální přípustný přesah
Lmax je ekvivalent maximální přípustné délky prstu, viz tabulka technických údajů.
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Repeat accuracy (gripping)
defined as the spread of the actual position at 100 consecutive closing or opening movements on a rigid workpiece or a fixed workpiece stop under constant conditions.
Repeat accuracy (positioning, unidirectional)
defined as the spread of the actual position of the base jaws after 100 consecutive movements to a target position from the same direction under constant conditions.
Repeat accuracy (positioning, bi-directional)
defined as the spread of the actual position of the base jaws after 100 consecutive movements to a target position from both directions under constant conditions.
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing and opening times
Minimum closing and opening times are merely the movement times of the base jaws or fingers at max. speed, max. acceleration, without current limitation (maximum current), and observance of the maximum permissible mass per finger.
Typical cycle time
is the time of a typical gripping cycle with pre-positioned gripper fingers 3 mm shortly before contacting the workpiece; this includes time intervals for closing and opening the gripper and for holding the workpiece. Idle times and times for locking and releasing the brake (EGI 80 only) are also taken into account.
Actuation
servo-electric, via brushless DC servomotors
Warranty
24 months
Scope of delivery
Gripper including safety information and accessory kit with centering sleeves for gripper and finger mounting. Product-specific instructions and software can be downloaded at schunk.com/downloads-manuals and schunk.com/downloads-software.