

EVG 55-40
ID 306020
- Hub pro Backe: 20 mm
- Min. Greifkraft: 5 N
- Max. Greifkraft: 24 N
- Spannungsversorgung: 24 V DC
- Max. Strom gesamt: 8 A
- Max. Umgebungstemperatur: 55 °C
Technical details
| Hub pro Backe [mm] | 20.0 |
|---|---|
| Min. Greifkraft [N] | 5.0 |
| Max. Greifkraft [N] | 24.0 |
| Empfohlenes Werkstückgewicht [kg] | 0.12 |
| Max. zulässige Fingerlänge [mm] | 125.0 |
| Max. zulässige Masse pro Finger [kg] | 0.1 |
| Wiederholgenauigkeit [mm] | ± 0.05 |
| Schließzeit [s] | 0.6 |
| Öffnungszeit [s] | 0.6 |
| Max. Geschwindigkeit [mm/s] | 300.0 |
| Max. Beschleunigung [mm/s²] | 10000.0 |
| Eigenmasse [kg] | 0.79 |
| Min. Umgebungstemperatur [°C] | 5.0 |
| Max. Umgebungstemperatur [°C] | 55.0 |
| Schutzart IP | 20 |
| Länge X [mm] | 100.0 |
| Breite Y [mm] | 55.0 |
| Höhe Z [mm] | 89.2 |
| Nennstrom [A] | 4.0 |
| Max. Strom [A] | 8.0 |
| Reglerelektronik | extern |
| Reglertyp | MCS-06 |
| Kommunikationsschnittstelle | siehe Regler MCS |
| Moment Mx max. [Nm] | 10.0 |
| Moment My max. [Nm] | 9.0 |
| Moment Mz max. [Nm] | 7.0 |
| Max. Kraft axial Fz max. [N] | 150.0 |
Dimensionen und max. Belastungen

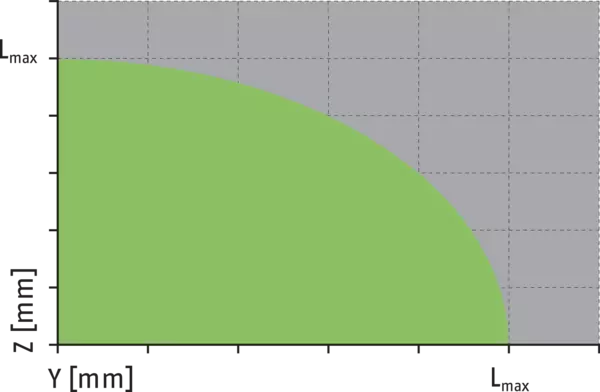
Maximal zulässige Auskragung

Greifkraft

Geschwindigkeit

Maximal zulässige Auskragung
Dimensionen und max. Belastungen
Die angegebenen Momente und Kräfte sind statische Werte, gelten je Grundbacke und dürfen gleichzeitig auftreten. Die Belastungen dürfen zusätzlich zu dem durch die Greifkraft erzeugten Moment auftreten.
Maximal zulässige Auskragung
Greifkraft
- X-axis:
- Punkt P – Fingerlänge
- Y-axis:
- Greifkraft
Geschwindigkeit
- X-axis:
- Hub
- Y-axis:
- Geschwindigkeit
Maximal zulässige Auskragung
Lmax entspricht der maximal zulässigen Fingerlänge, siehe technische Datentabelle.
- green
- Zulässiger Bereich
- grey
- Unzulässiger Bereich
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy
is defined as a distribution of the end Position for 100 consecutive strokes.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing and opening times
Minimum closing and opening times are merely the movement times of the base jaws or fingers at max. speed, max. acceleration, without current limitation (maximum current), and observance of the maximum permissible mass per finger.
Nominal currents
can be permanently actuated. With regard to all the currents which are ranging above the nominal current up to the maximum current, the notes of the individual product documentation has to be respected.
Electrical brake
The built-in, electric holding break is used for fixing and holding the position of the gripper jaws in the event of a power failure. It cannot cover all of the security or gripping force maintenance functions.
Operating principle
Belt drive
Housing material
Aluminum alloy, coated
Base jaw material
Aluminum alloy, anodized
Actuation
servo-electric, via brushless DC servomotor
Warranty
24 months
Scope of delivery
Enclosed accessory pack with centering sleeve, assembly and operating manual with declaration of incorporation. An external controller MCS-06 is required for operating the gripper EVG The connection cable with a length of 3 meters is attached to the gripper. The controller is optionally available and is not included in the scope of not included.