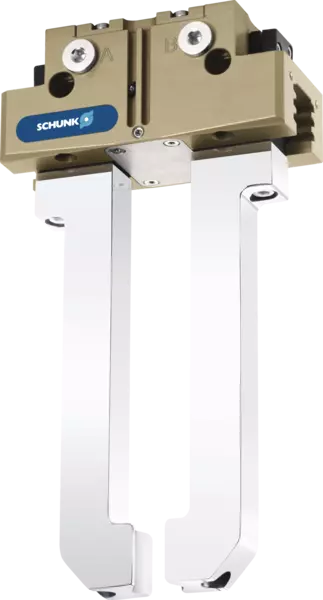
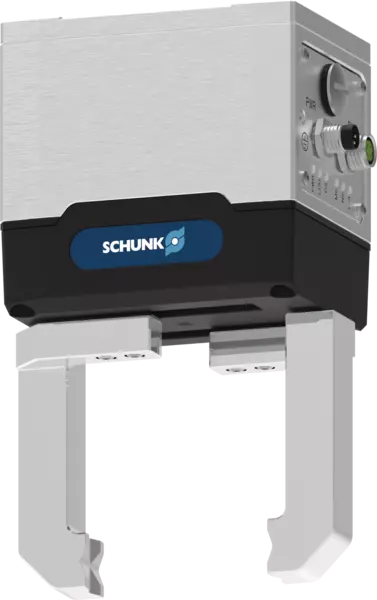
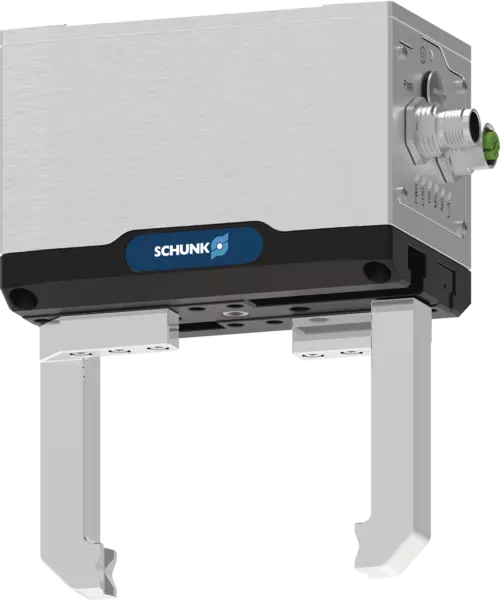
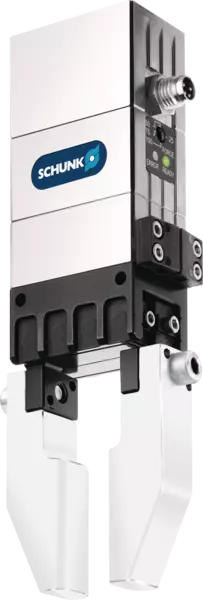
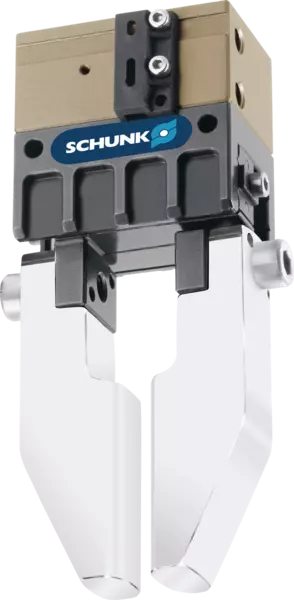
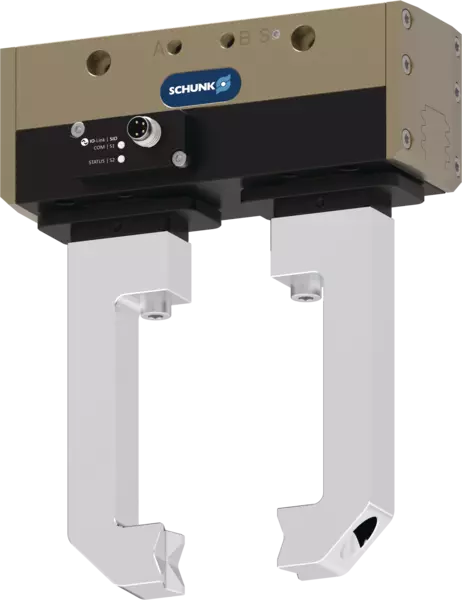
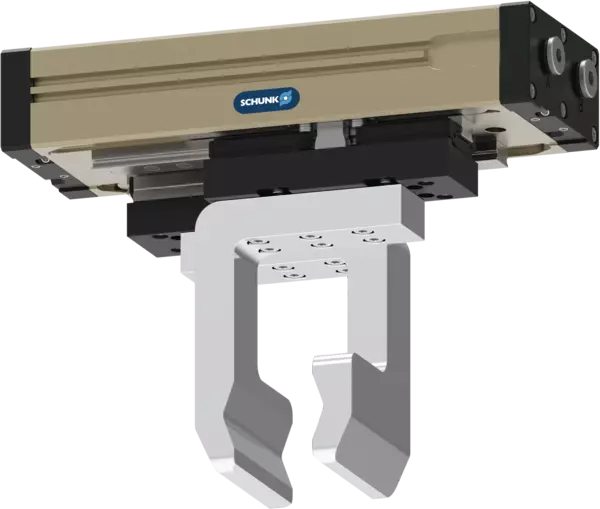
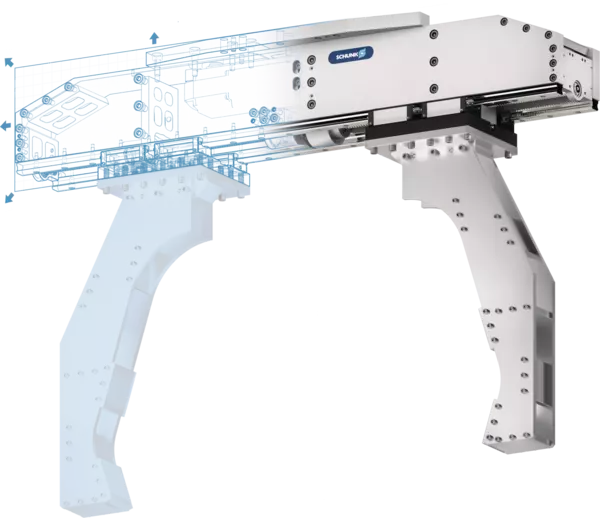
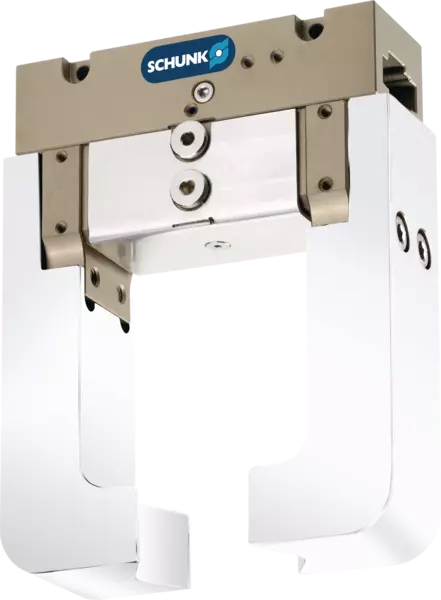
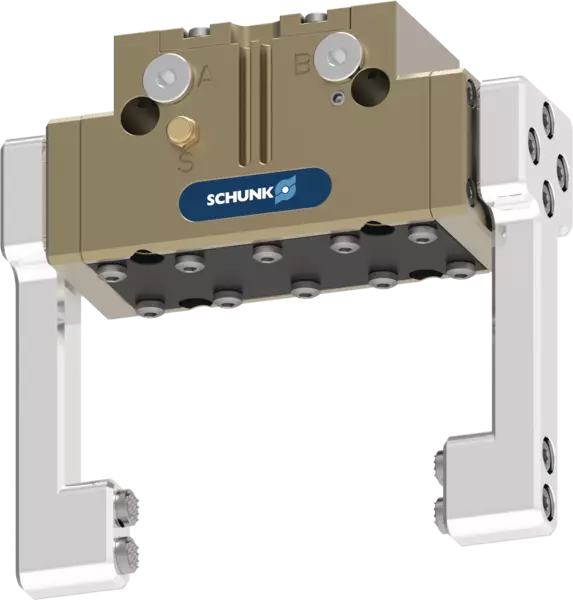
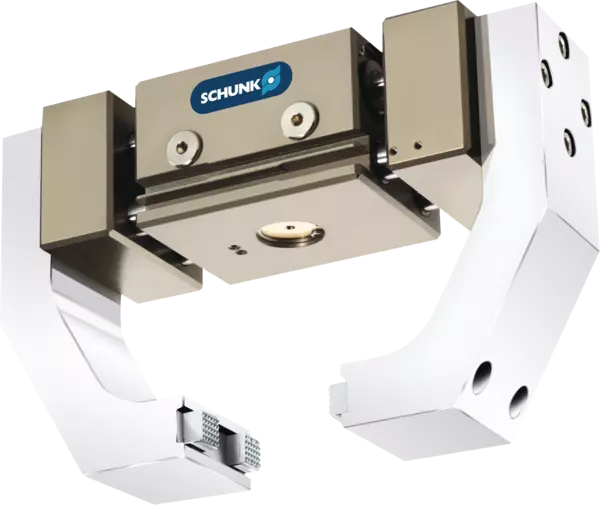
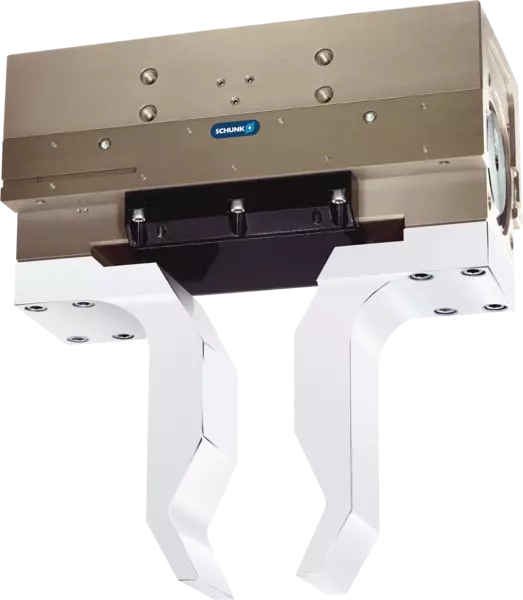
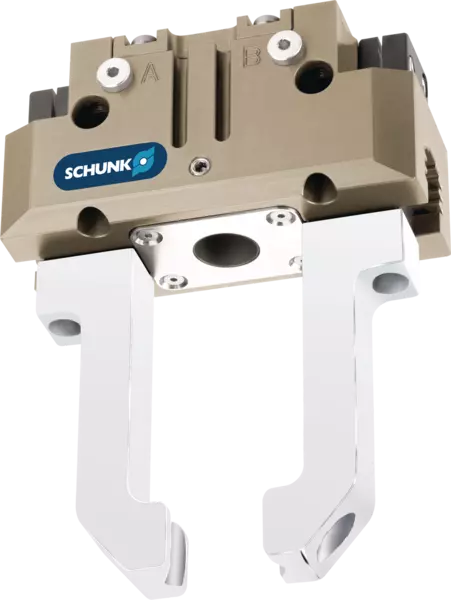
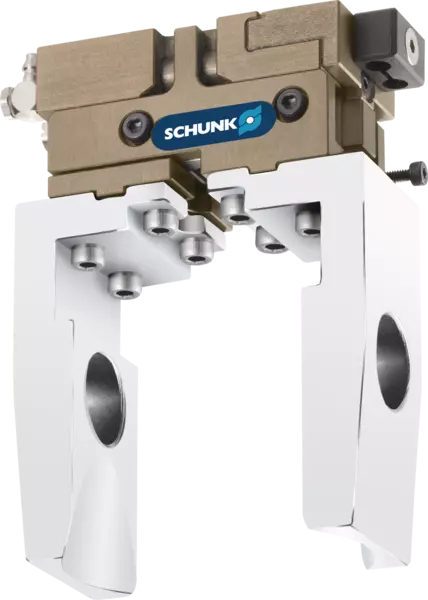
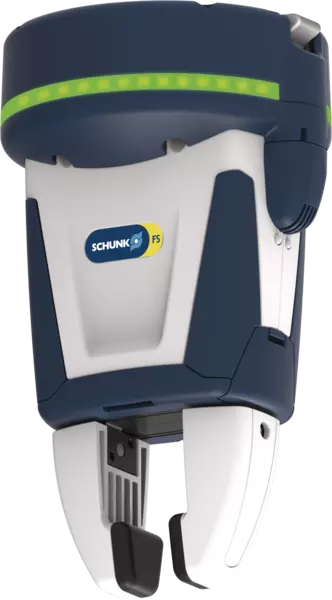
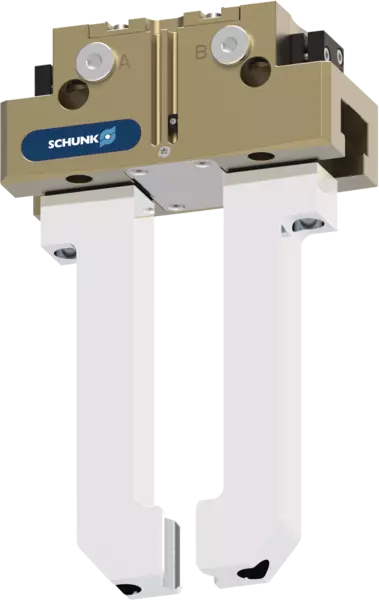
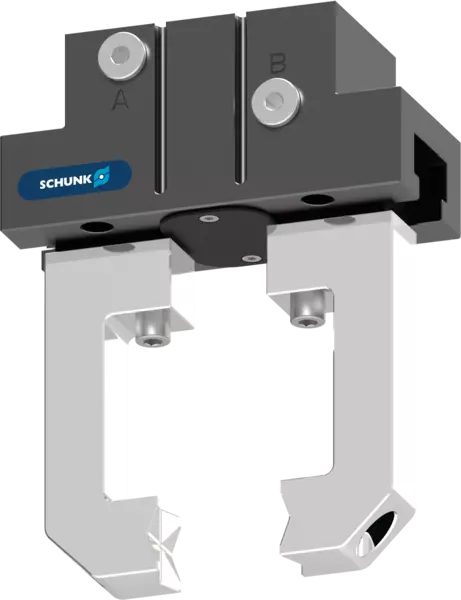
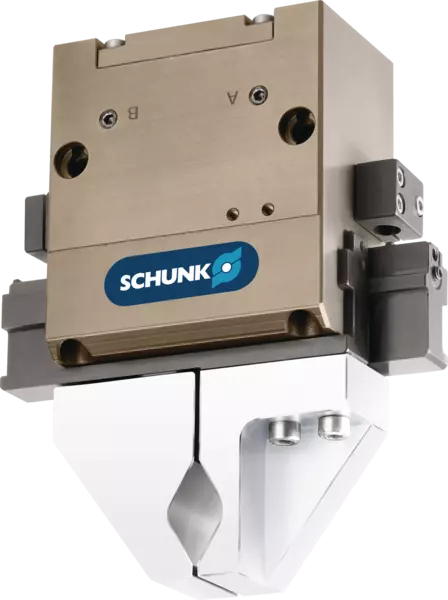
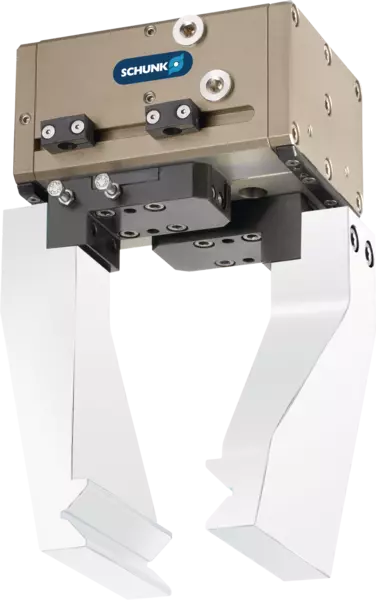
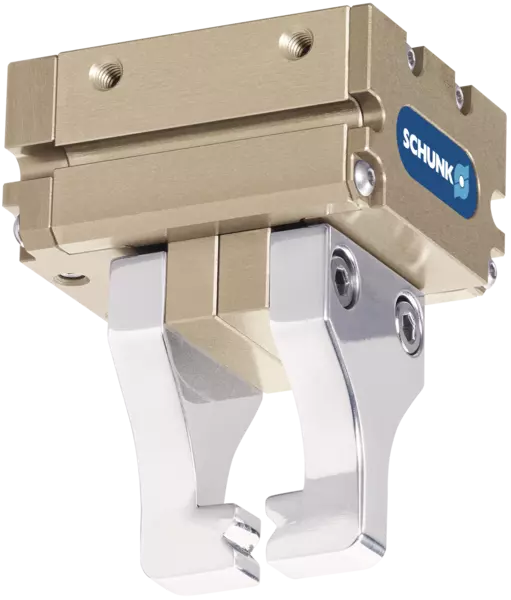
Nossas garras paralelas padrão incluem garras pequenas, universais, de longo curso e vedadas para manuseio seguro e preciso de peças. Eles podem manusear peças com pesos entre alguns gramas e 80 kg e são adequados para muitas aplicações, desde salas limpas até áreas de trabalho potencialmente explosivas. A capacidade de equipar as garras com sistemas de sensores indutivos, chaves magnéticas ou garras específicas para peças melhora sua funcionalidade, confiabilidade do processo e produtividade. Além disso, ajustes de design inovadores, como guia multidentada, são combinados com tecnologia de produção de última geração para torná-los robustos e confiáveis e, portanto, um investimento seguro com uma longa vida útil.
In the event of energy or pressure loss, seven variants secure the gripping force and/or the current position:
AS (spring closing)/IS (spring opening): A spring holds the gripper closed or open with minimum force. S (spring closing/opening): Depending on the design of the top jaws, the spring acts as a closing or opening mechanism. ASC (certified spring closing)/ISC (certified spring opening): The certified GripGuard gripping force maintenance ensures at least 80% gripping force in the closing or opening direction in the event of a pressure drop. M (permanent magnetic brake): Maintains the gripping force in the closing and opening direction. KP (position clamping): Fixes the current position in the closing and opening direction – via a brake or a pneumatic clamping element.
The ambient temperature describes the temperature of the air or the direct operating environment in which a gripper is operated (and not the workpiece temperature, as this is normally significantly higher than the ambient temperature). We also offer special solutions for ambient temperatures above 130 °C. We would be happy to review your use case based on your specific process data.
is calculated for force-fit clamping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. In the case of form-fit gripping, significatnly higher permissible workpiece weights are possible.
Example: - For the catalog-specified workpiece weight of 5 kg Gripping force of the gripper 1,000 N Coefficient of friction μ 0.1; safety factor 2; g 9.81
For supported robot systems, we provide specific adapter plates, cable kits, and software plug-ins. This simplifies a standardized mechanical connection as well as software commissioning and integration. Is your target system not listed? Please contact us!
For supported control systems, we provide specific software resources (e.g., function blocks or parameter sets). This simplifies software commissioning and integration. Is your target system not listed? Please contact us!