EZU
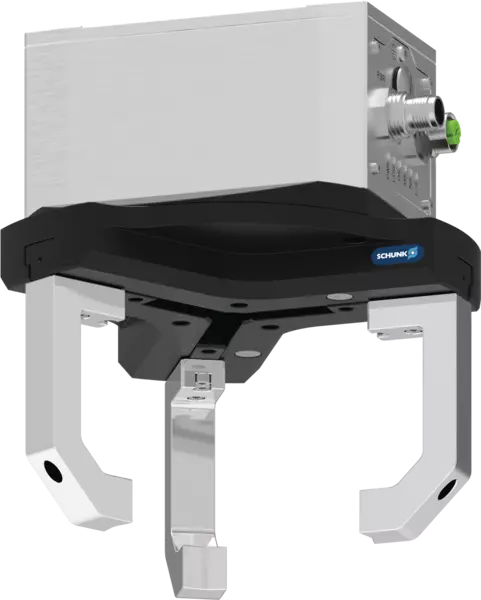
The powerful expert in centering.
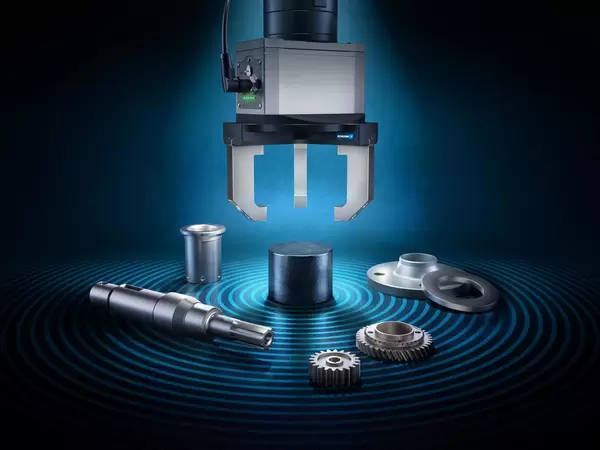
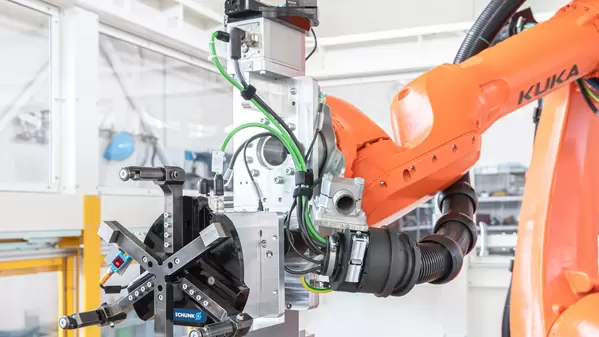
The EZU electric centric gripper was developed for challenging handling tasks. Due to its high gripping forces and robust design, it can reliably handle workpieces even under demanding production conditions and under heavy loads.
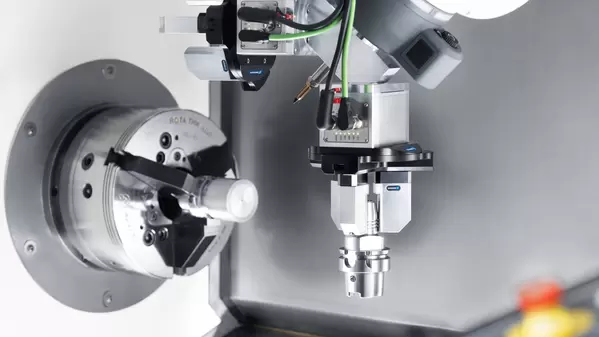
EZU in action
What makes the EZU special
Eén grijper voor een breed spectrum van werkstukken
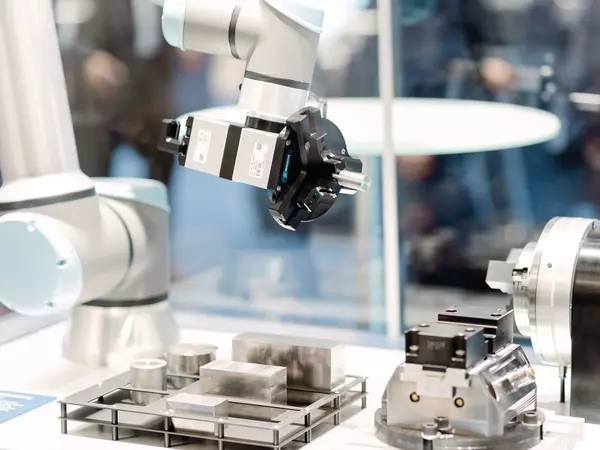
Grote en zware werkstukken brengen vaak allerhande uitdagingen met zich mee met betrekkking tot hun handling. Grijpkracht en slag kan flexibel worden ingesteld, zodat een enkele grijper een grote verscheidenheid van werkstukken kan hanteren. Dit vermindert de vereiste inspanningen voor omschakelingen en vereenvoudigt geautomatiseerde processen.
Ga snel en ongecompliceerd van start
De EZU wordt geïntegreerd met gestandardiseerde communicatie-interfaces, roboticaplug-in en vooraf geconfigueerde functieblokken. Dit maakt het mogelijk om nieuwe toepassingen snel te implementeren en bestaande systemen gemakkelijk uit te breiden.
Hoge betrouwbaarheid van het proces in de uitvoeringsfase
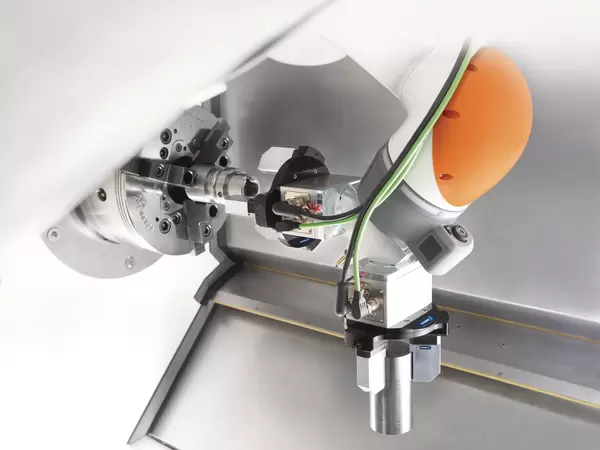
Bij de handling van grote en zware werkstukken is betrouwbaarheid cruciaal. Grijpkrachtbehoud, detectie van verlies van werkstuk en robuuste geleidingen garanderen dat werkstukken stevig worden gegrepen en verplaatst, zelfs onder hoge belastingen.
The benefits at a glance.
- Reliably handle workpieces even under demanding industrial conditions due to their robust design, which can withstand dust, coolant and heavy loads.
- Handle a wide variety of workpieces using just one gripper, due to the large stroke range and continuously adjustable gripping force.
- Get started quickly and easily with a wide range of communication interfaces and comprehensive support, including robot plugins, PLC modules, open-source components, models for virtual commissioning, and the commissioning app in the SCHUNK Control Center.
- High process reliability even under high forces and torques, due to the heavy-duty T-slot sliding guide as well as integrated gripping force maintenance and workpiece loss detection.
- Systematically avoid interfering contours and speed up gripping processes by the parallel approach to a freely selectable pre-position even while the machine is still in motion.
- Continue working immediately after a restart, without the need for a reference run, due to a high-resolution absolute encoder.
- Grip and re-grip workpieces even in the event of positional deviations and tolerances without requiring additional approach travel through autonomous centering and controlled build-up of the gripping force via the drive.
- Control and monitor the gripping process precisely using customizable motion and handling functions, as well as status, error and warning messages.
- Virtually maintenance-free due to the use of brushless flat motors.