EZU
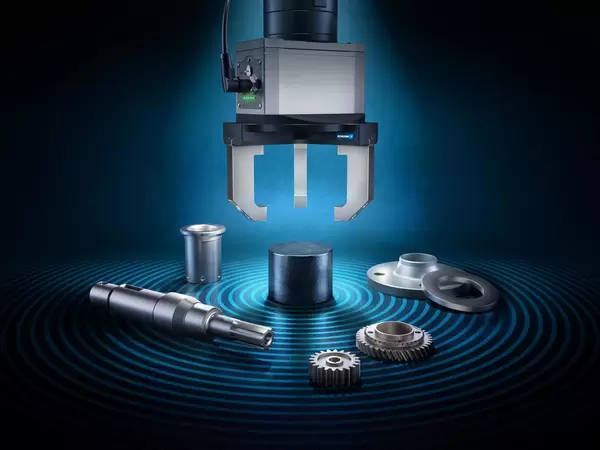
The powerful expert in centering.
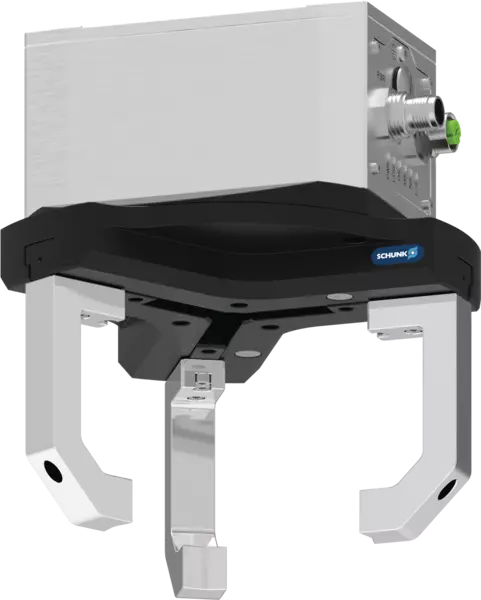
The EZU electric centric gripper was developed for challenging handling tasks. Due to its high gripping forces and robust design, it can reliably handle workpieces even under demanding production conditions and under heavy loads.
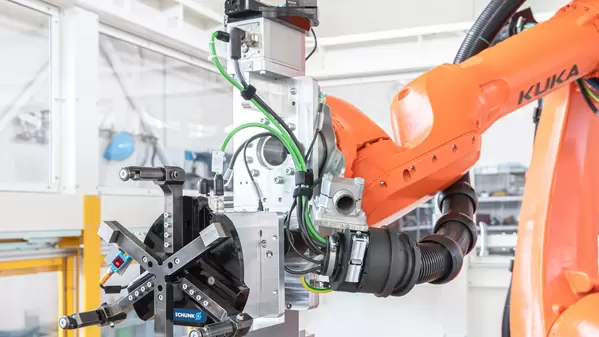
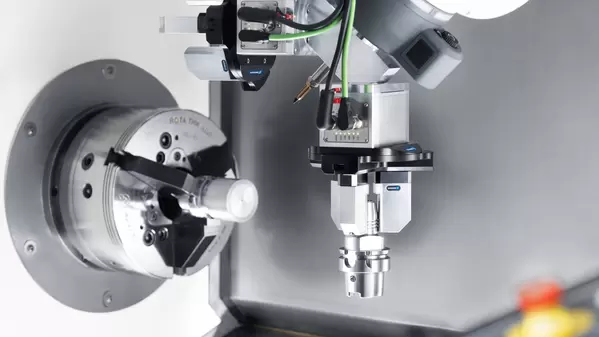
EZU in action
What makes the EZU special
Una pinza para una amplia variedad de piezas
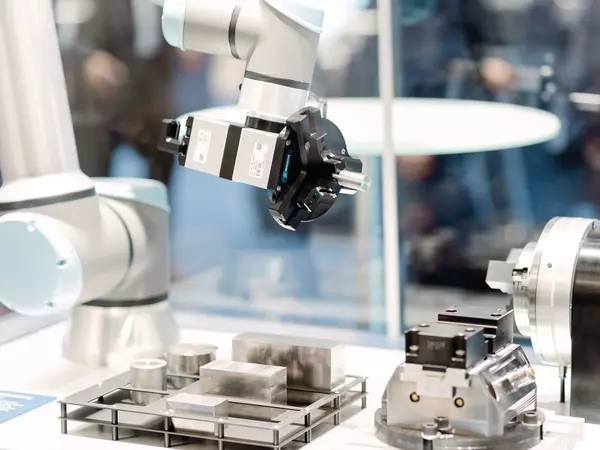
Las piezas de gran tamaño y peso suelen plantear diversos retos a la hora de manipularlas. La fuerza de agarre y la carrera se pueden ajustar de forma flexible, lo que permite que una sola pinza pueda manipular una gran variedad de piezas. Esto reduce el esfuerzo necesario para los cambios y simplifica los procesos automatizados.
Empiece de forma rápida y sencilla
El EZU se integra mediante interfaces de comunicación estandarizadas, complementos de robótica y bloques funcionales preconfigurados. Esto permite implementar nuevas aplicaciones con rapidez y ampliar los sistemas existentes con facilidad.
Alta seguridad del proceso en funcionamiento
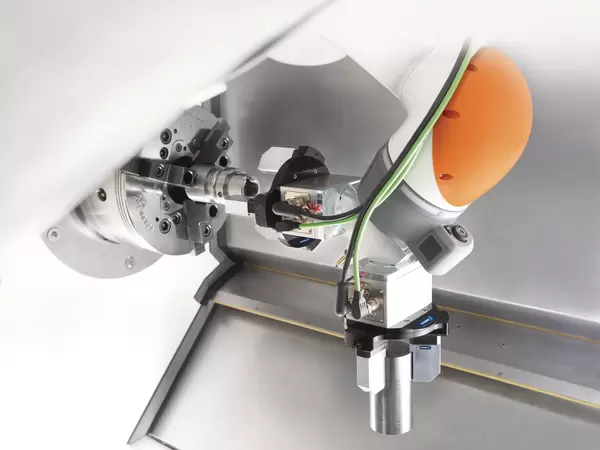
A la hora de manipular piezas grandes y pesadas, la seguridad es fundamental. La posición fuerza de agarre, la detección de la pérdida de piezas y las guías resistentes garantizan que las piezas puedan agarrarse y desplazarse de forma segura incluso con cargas elevadas.
The benefits at a glance.
- Reliably handle workpieces even under demanding industrial conditions due to their robust design, which can withstand dust, coolant and heavy loads.
- Handle a wide variety of workpieces using just one gripper, due to the large stroke range and continuously adjustable gripping force.
- Get started quickly and easily with a wide range of communication interfaces and comprehensive support, including robot plugins, PLC modules, open-source components, models for virtual commissioning, and the commissioning app in the SCHUNK Control Center.
- High process reliability even under high forces and torques, due to the heavy-duty T-slot sliding guide as well as integrated gripping force maintenance and workpiece loss detection.
- Systematically avoid interfering contours and speed up gripping processes by the parallel approach to a freely selectable pre-position even while the machine is still in motion.
- Continue working immediately after a restart, without the need for a reference run, due to a high-resolution absolute encoder.
- Grip and re-grip workpieces even in the event of positional deviations and tolerances without requiring additional approach travel through autonomous centering and controlled build-up of the gripping force via the drive.
- Control and monitor the gripping process precisely using customizable motion and handling functions, as well as status, error and warning messages.
- Virtually maintenance-free due to the use of brushless flat motors.