
Pince collaborative – Co-act meets cobots
Une interaction intelligente et sécurisée avec les personnes
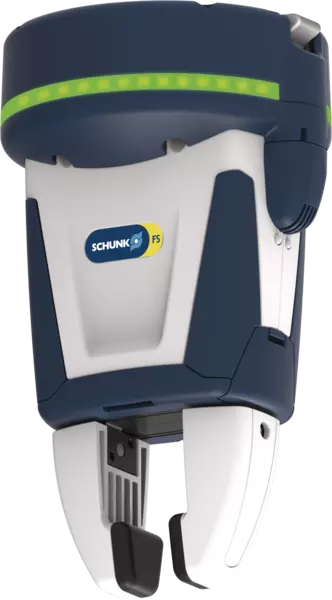
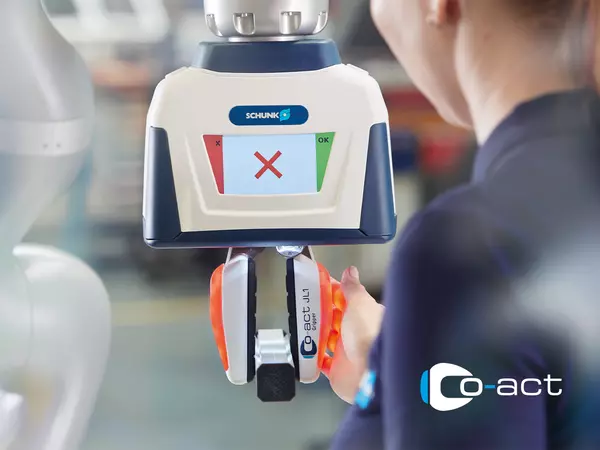
SCHUNK sets benchmarks – also in human-robot collaboration (HRC). As a pioneer, SCHUNK launched the Co-act EGP-C. The first certified industrial gripper for collaborative operation on the market.
SCHUNK received the Hermes Award, one of the most coveted technology prizes in the world, at the Hannover Messe 2017 for the Co-act JL1 gripper, the world's first gripping module for human-robot collaboration that interacts and communicates directly with humans, Become a part of this groundbreaking technology and join us on the way to human-robot collaboration.
Entièrement nouveau :
Food-grade lubrication
The product contains food-compliant lubricants as standard. The requirements of standard EN 1672-2:2020 are not fully met. The corresponding NSF certificates can be found at https://info.nsf.org/USDA/Listings.asp can be called up with the help of the lubricant information in the operating manual.
Components such as rolling bearings, linear guides, or shock absorbers are not provided with food-compliant lubricants.
Comment trouver la pince optimale pour votre application
Step 1
Task description and feasibility check
- Are the task and workpiece suitable for human-robot collaboration?
Step 2
Selection of the robot or cobot
- Definition of the basic system with mechanical and electrical connection of the peripheral devices
- Ensuring a defined control
Step 3
Selecting the gripper in collaboration with the SCHUNK Co-act team considering the following points:
- Workpiece with regard to gripping position, required gripping force, and necessary stroke
- Pick and place position and in turn analysis of the interfering contour
- Connection to the superordinate mechanical and electric periphery
- Clamping and shear points on the gripper or the attachment fingers
Vous avez actuellement à relever un défi HRC spécifique et vous souhaitez en apprendre plus sur les pinces HRC de SCHUNK ?
Veuillez nous contacter pour vos demandes personnalisées.
Intéressé(e) ?
