
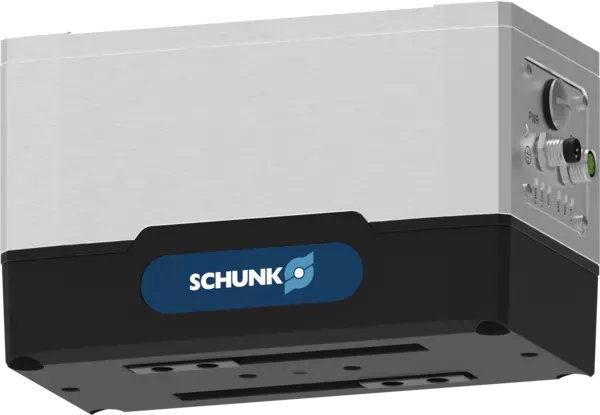
EGK 50-EI-N-B
小元件抓取机械手
ID 1491781
小元件抓取机械手 EGK, 尺寸: 50, 电动, 通信接口: EtherNet/IP
- 单指行程: 51.5 mm
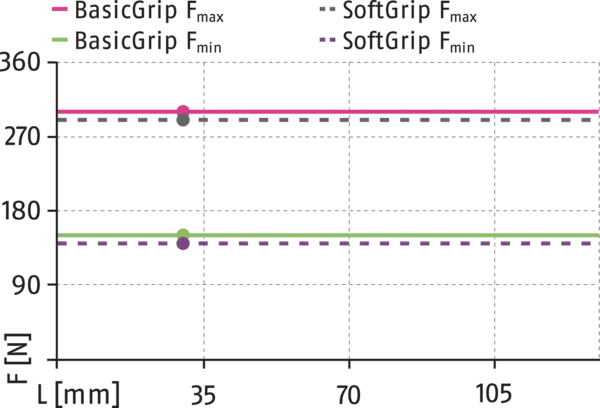
- 最小抓取力: 150 N
- 最大抓取力: 300 N
- 能源供应: 24 V
- 最高环境温度: 55 °C
技术细节
| Stroke per jaw [mm] | 51.5 |
|---|---|
| Min. gripping force [N] | 150.0 |
| Max. gripping force [N] | 300.0 |
| Max. permissible finger length [mm] | 130.0 |
| Max. permissible weight per finger [kg] | 0.5 |
| Positioning accuracy [mm] | ± 0.3 |
| Repeat accuracy (gripping) [mm] | 0.03 |
| Repeat accuracy (positioning, unidirectional) [mm] | 0.1 |
| Repeat accuracy (positioning, bi-directional) [mm] | 0.2 |
| Closing time [s] | 0.54 |
| Opening time [s] | 0.54 |
| Max. speed (positioning) [mm/s] | 130.0 |
| Max. acceleration [mm/s²] | 1000.0 |
| Weight [kg] | 1.59 |
| Min. ambient temperature [°C] | 5.0 |
| Max. ambient temperature [°C] | 55.0 |
| IP protection class, electronics | 67 |
| IP protection class guide/base jaws | 20 |
| Cleanroom class ISO 14644-1 | 5 |
| Cleanroom class: ISO 14644-1 | 2015 |
| Length X [mm] | 147.0 |
| Width Y [mm] | 78.0 |
| Height Z [mm] | 90.0 |
| Nominal voltage [V] | 24.0 |
| Communication interface | EtherNet/IP |
| Power nominal current consumption [A] | 0.22 |
| Power max. current consumption [A] | 0.82 |
| Logic nominal current consumption [A] | 0.16 |
| Logic max. current consumption [A] | 0.2 |
| Moment Mx max. [Nm] | 9.0 |
| Moment My max. [Nm] | 9.0 |
| Moment Mz max. [Nm] | 5.0 |
| Max. axial force Fz max. [N] | 700.0 |
| Version without gripping force maintenance | yes |
尺寸和最大载荷

最大允许手指投影

Gripping modes

Gripping force
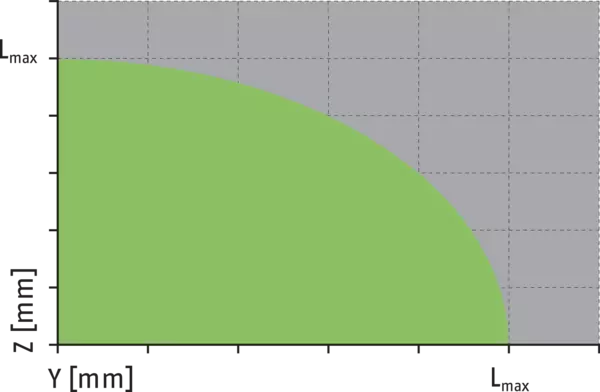
Maximum permitted finger projection
尺寸和最大载荷
所示力矩和力为静态值,适用于每个基爪,且可能会同时出现。除抓取力自身产生的力矩外,还可能产生负载。
最大允许手指投影
Gripping modes
- X 轴:
- Travel times
- Y 轴:
- Gripping force
Gripping force
- X 轴:
- Finger length
- Y 轴:
- Gripping force
Maximum permitted finger projection
Lmax is equivalent to the maximum permitted finger length, see the technical data table.
- green
- Permitted range
- grey
- Inadmissible range
产品系列的常规说明
抓取力
在距离 P(请参见插图)处施加到每个机械手夹爪的抓取力的算术和。
重复精度(抓取)
指在恒定条件下,对刚性工件或测试件进行 100 次连续闭合或打开运动时,每个卡爪实际位置的偏差范围。
重复精度(单向定位)
在恒定条件下,连续 100 次从相同的方向移动到目标位置后各基爪的实际位置分布而得出。
重复精度(双向定位)
在恒定条件下,连续 100 次从两个方向移动到目标位置后各基爪的实际位置分布而得出。
手指长度
沿主轴方向,从距基准面距离 P 处测得。
定位精度
在恒定条件下,连续 100 次单向移动到目标位置后各卡爪的实际位置偏差而得出。
闭合/打开时间(定位)
闭合和打开时间指在不超过每个手指的最大允许重量的情况下,在最大速度和最大加速度下的机械手手指的运动时间,并参考各手指的移动路径和额定行程的 50%。
最高速度(定位)和最大加速度
是作用于每个爪的速度和加速度的算术和。
外壳材料
铝合金,阳极氧化
基爪材料
硬质阳极氧化高强度铝
保修期
12 个月或 500 万次循环(一个循环包含一个完整的抓取过程:“打开机械手”和“闭合机械手”)
标配范围
机械手包括安全信息和随附套件,配有用于机械手和手指安装的定心套。关于特定产品的说明和软件,可以前往 schunk.com/downloads-manuals 和 schunk.com/downloads-software 下载。