EZN 64-S
Ident.-Nr. 306113
Alternative Produkte:
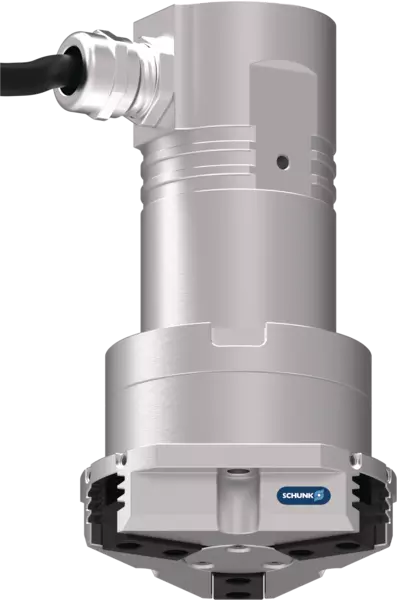
- 单指行程: 6 mm
- 最小抓取力: 140 N
- 最大抓取力: 500 N
- 能源供应: 24 V
- 最大总电流: 4 A
- 最高环境温度: 55 °C
Technische Details
| 单指行程 [mm] | 6.0 |
|---|---|
| 最小抓取力 [N] | 140.0 |
| 最大抓取力 [N] | 500.0 |
| 建议工件重量 [kg] | 2.5 |
| 最大允许手指长度 [mm] | 80.0 |
| 每个手指的最大允许重量 [kg] | 0.35 |
| 重复精度 [mm] | ± 0.01 |
| 最小空气吹扫压力 [bar] | 0.5 |
| 最大空气吹扫压力 [bar] | 1.0 |
| 闭合时间 [s] | 0.25 |
| 打开时间 [s] | 0.25 |
| 最大速度 [mm/s] | 80.0 |
| 最大加速度 [mm/s²] | 1500.0 |
| 重量 [kg] | 0.98 |
| 最低环境温度 [°C] | 5.0 |
| 最高环境温度 [°C] | 55.0 |
| IP 防护等级 | 41 |
| 直径 D [mm] | 70.5 |
| 高度 Z [mm] | 133.5 |
| 额定电流 [A] | 1.4 |
| 最大电流 [A] | 4.0 |
| 控制器电子元件 | 外部 |
| 控制器类型 | ECM-EZN064 |
| 通信接口 | 参见控制器 ECM |
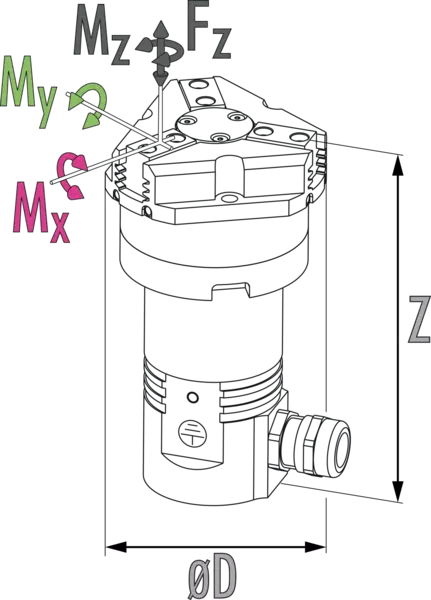
| 力矩 Mx max. [Nm] | 40.0 |
| 力矩 My max. [Nm] | 60.0 |
| 力矩 Mz max. [Nm] | 40.0 |
| 最大轴向力 Fz max。 [N] | 1100.0 |
Dimensions and maximum loads
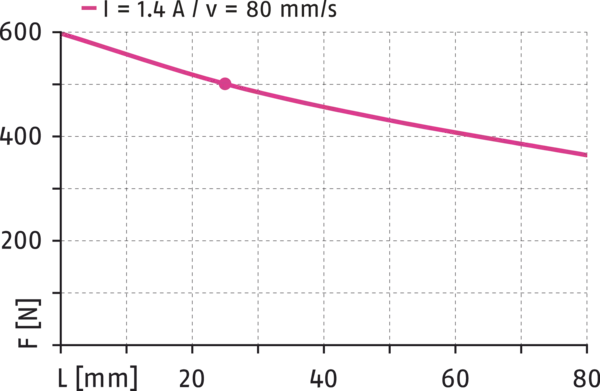
抓取力
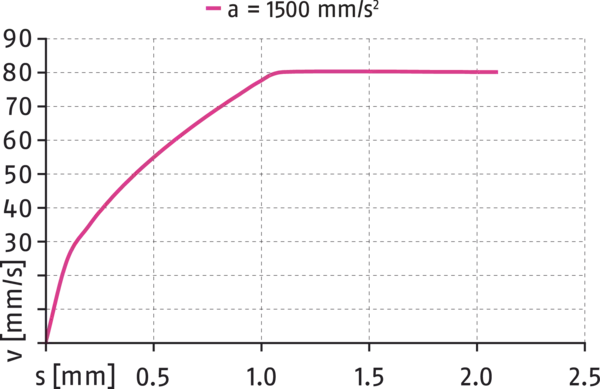
Speed
Dimensions and maximum loads
The indicated moments and forces are statical values, apply for each base jaw and may appear simultaneously. Loads may additionally occur to the moment produced by the gripping force itself.
抓取力
- X-Achse:
- Point P - Finger length
- Y-Achse:
- Gripping force
Speed
- X-Achse:
- Stroke
- Y-Achse:
- Speed
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy
is defined as a distribution of the end Position for 100 consecutive strokes.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing and opening times
Minimum closing and opening times are merely the movement times of the base jaws or fingers at max. speed, max. acceleration, without current limitation (maximum current), and observance of the maximum permissible mass per finger.
Nominal currents
can be permanently actuated. With regard to all the currents which are ranging above the nominal current up to the maximum current, the notes of the individual product documentation has to be respected.
Wirkprinzip
Keilhakenkinematik
Gehäusematerial
Aluminiumlegierung, oberflächenveredelt
Grundbackenmaterial
Stahl
Betätigung
servoelektrisch, über bürstenlosen DC-Servomotor und Spindelantrieb
Gewährleistung
24 Monate
Lebensdauerkennwerte
auf Anfrage
Lieferumfang
Greifer inklusive Sicherheitsinformationen und Beipack mit Zentrierhülsen für Greifermontage und Fingermontage. Produktspezifische Anleitungen und Software können unter schunk.com/downloads-manuals und schunk.com/downloads-software heruntergeladen werden.