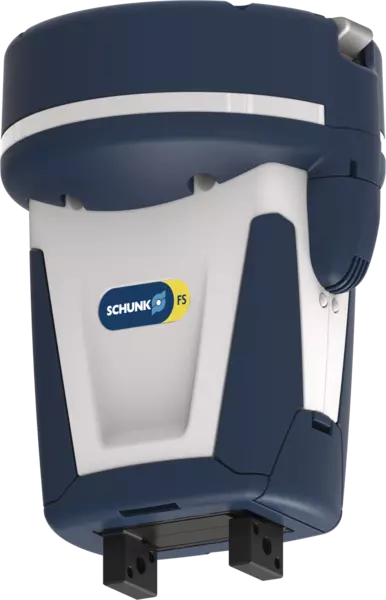
Co-act EGP-C 40-N-N-FCR7
ID 1326456
- Carrera por mordaza: 6 mm
- Fuerza de agarre mín.: 35 N
- Fuerza de agarre máx.: 140 N
- Suministro de energía: 24 V
- Corriente máxima total: 2 A
- Temperatura ambiente máx.: 55 °C
Technical details
| Compatible con robot | FANUC CR-7 iA |
|---|---|
| Brida del robot | Brida estándar |
| Franja luminosa LED | integrada |
| Colores visualizables | verde, amarillo y rojo |
| Sensores integrados | sí, inductivo en dos direcciones |
| Longitud X [mm] | 93.8 |
| Anchura Y [mm] | 90.2 |
| Altura Z [mm] | 120.5 |
| Carrera por mordaza [mm] | 6.0 |
| Fuerza de agarre mín. [N] | 35.0 |
| Fuerza de agarre máx. [N] | 140.0 |
| Fuerza mín. por mordaza [N] | 17.5 |
| Fuerza máx. por mordaza [N] | 70.0 |
| Peso recomendado de la pieza [kg] | 0.7 |
| Longitud máxima admisible de los dedos [mm] | 50.0 |
| Peso máx. admisible por dedo [kg] | 0.08 |
| Precisión de repetición [mm] | 0.02 |
| Tiempo de cierre [s] | 0.2 |
| Tiempo de apertura [s] | 0.2 |
| Peso [kg] | 0.66 |
| Temperatura ambiente mín. [°C] | 5.0 |
| Temperatura ambiente máx. [°C] | 55.0 |
| Clase de protección IP | 30 |
| Conector/final de cable | cables abiertos |
| Longitud del cable [mm] | 1000.0 |
| Voltaje nominal [V] | 24.0 |
| Corriente nominal [A] | 0.2 |
| Corriente máx. [A] | 2.0 |
| Sistema electrónico de control | integrada |
| Interfaz de comunicación | E/S digital |
| Señal digital de potencia Número de entradas digitales | 4.0 |
| Número de salidas digitales | 2.0 |
| Momento Mx máx. [Nm] | 1.5 |
| Momento My máx. [Nm] | 2.0 |
| Momento Mz máx. [Nm] | 4.0 |
| Máx. fuerza axial Fz máx. [N] | 170.0 |
Dimensiones y cargas máximas
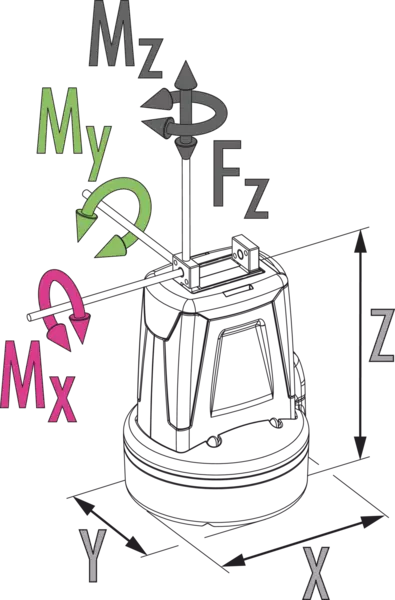
Máxima proyección permitida de los dedos
Fuerza de agarre
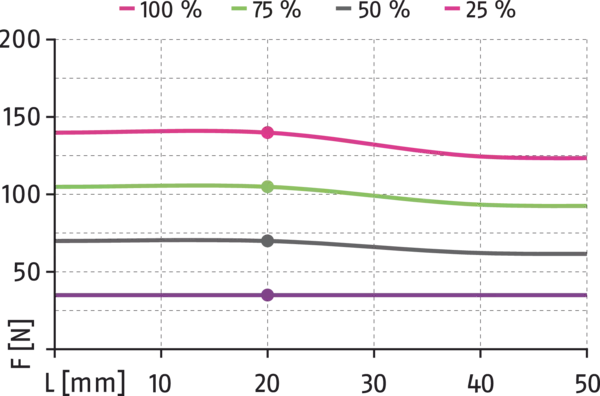
Máxima proyección permitida de los dedos
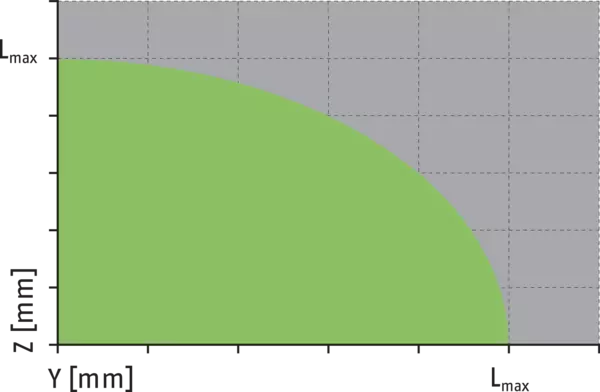
Dimensiones y cargas máximas
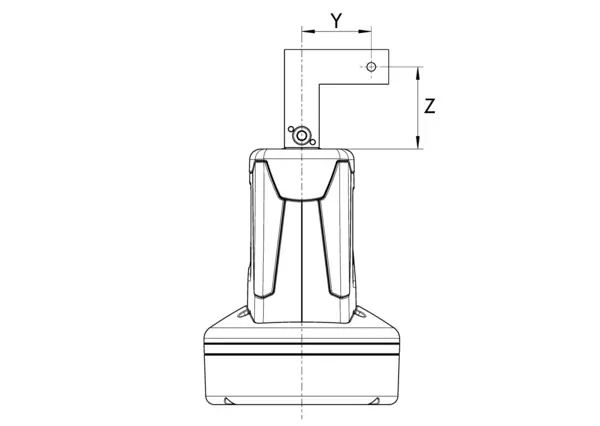
Las fuerzas y los momentos indicados son valores estáticos que se aplican por garra base y deben darse simultáneamente. Adicionalmente podrían producirse cargas en el momento generado por la fuerza de agarre.
Máxima proyección permitida de los dedos
Fuerza de agarre
- X-axis:
- Longitud de las garras
- Y-axis:
- Fuerza de agarre
Máxima proyección permitida de los dedos
Lmax equivale a la longitud de dedo máxima permitida (consulte la tabla de datos técnicos).
- green
- Margen admisible
- grey
- Margen inadmisible
General notes about the series
Gripping force
is the arithmetic total of the gripping force applied to each gripper jaw at distance P (see illustration). For more information, see the detailed functional description.
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy
is defined as a distribution of the end Position for 100 consecutive strokes.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights. For more information, see sssembly and operating manual.
Closing and opening times
are movement times of the base jaws only, without application-specific gripper fingers. PLC reaction times are not included in the above-mentioned times and must be taken into consideration when determining cycle times.
Operating principle
Rack and pinion principle
Housing material
Polyamide with glass fiber additive
Base jaw material
Steel
Actuation
servo-electric, via brushless DC servomotor
Warranty
see assembly and operating manual
Service life characteristics
on request
Scope of delivery
Accessory pack with adapter flange, mounting material and hexagon socket wrench, assembly and operating manual with declaration of conformity and incorporation, safety information