
EGP 40-N-S-B
ID 310942
- Skok na szczękę: 6 mm
- Min. siła chwytania: 30 N
- Maks. siła chwytania: 30 N
- Czas otwierania: 0.06 s
- Czas zamykania: 0.06 s
- Zasilanie: 24 V
- Maks. prąd całkowity: 2 A
- Maks. temperatura otoczenia: 55 °C
Technical details
| Skok na szczękę [mm] | 6.0 |
|---|---|
| Min. siła chwytania [N] | 30.0 |
| Maks. siła chwytania [N] | 30.0 |
| Zalecana masa detalu [kg] | 0.15 |
| Maks. dopuszczalna długość palca [mm] | 50.0 |
| Maks. dopuszczalna masa na palec [kg] | 0.08 |
| Powtarzalność (chwytu) [mm] | 0.02 |
| Czas zamykania [s] | 0.06 |
| Czas otwierania [s] | 0.06 |
| Masa [kg] | 0.3 |
| Min. temperatura otoczenia [°C] | 5.0 |
| Maks. temperatura otoczenia [°C] | 55.0 |
| Stopień ochrony IP | 30 |
| Klasa pomieszczenia sterylnego ISO 14644-1 | 5 |
| Klasa pomieszczenia sterylnego: ISO 14644-1 | 1999 |
| Emisja hałasu [dB(A)] | < 70 |
| Długość X [mm] | 40.0 |
| Szerokość Y [mm] | 26.0 |
| Wysokość Z [mm] | 88.4 |
| Napięcie znamionowe [V] | 24.0 |
| Prąd znamionowy [A] | 0.2 |
| Maks. prąd [A] | 2.0 |
| Elektroniczny układ sterownika | zintegrowany |
| Interfejs komunikacyjny | Cyfrowe we/wy |
| Numer wejść cyfrowych | 2.0 |
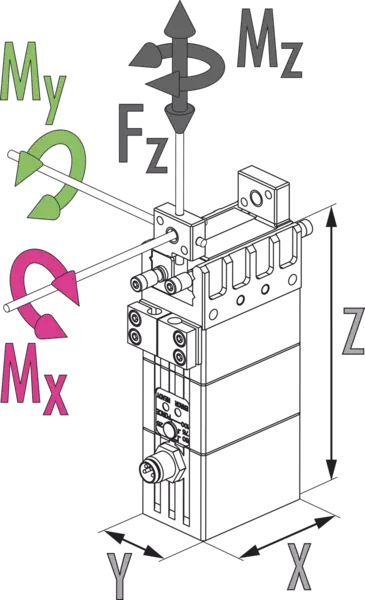
| Moment Mx maks. [Nm] | 1.5 |
| Moment My maks. [Nm] | 2.0 |
| Moment Mz maks. [Nm] | 4.0 |
| Maks. siła osiowa Fz maks. [N] | 170.0 |
Dimensões e cargas máximas
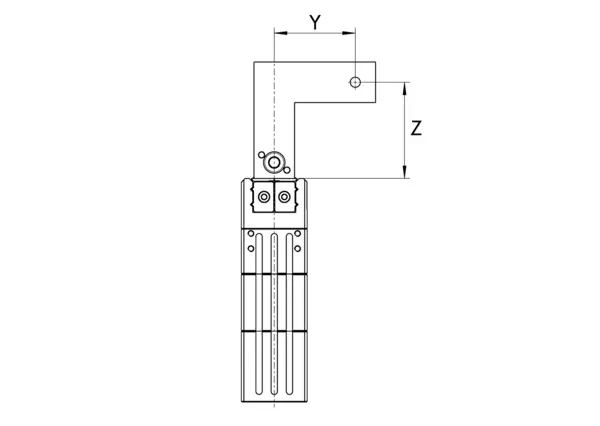
Projeção máxima permitida do dedo
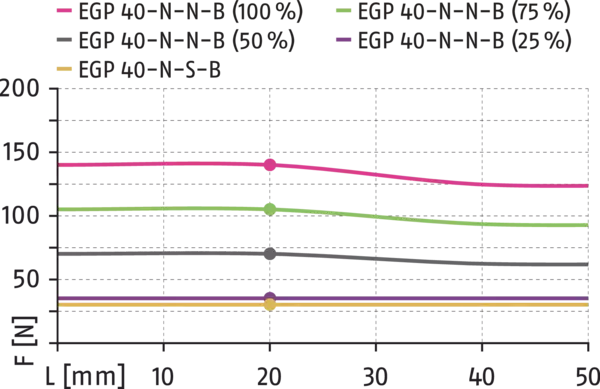
Força de preensão
Projeção máxima permitida do dedo
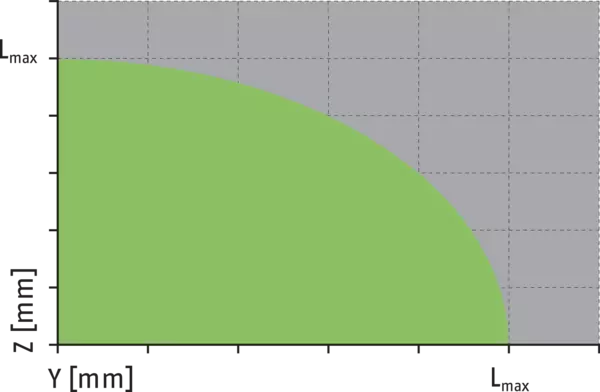
Dimensões e cargas máximas
Os momentos e forças indicados são valores estáticos, aplicam-se a cada castanha base e podem aparecer simultaneamente. As cargas podem ocorrer adicionalmente ao momento produzido pela própria força de preensão.
Projeção máxima permitida do dedo
Força de preensão
- X-axis:
- Comprimento do dedo
- Y-axis:
- Força de preensão
Projeção máxima permitida do dedo
Lmax é equivalente ao comprimento máximo permitido do dedo, consulte a tabela de dados técnicos.
- green
- Faixa permitida
- grey
- Faixa inadmissível
General notes about the series
Gripping force
is the arithmetic sum of the individual force applied to each jaw at distance P (see illustration).
Finger length
is measured from the reference surface as the distance P in direction to the main axis.
Repeat accuracy (gripping)
defined as the spread of the actual position at 100 consecutive closing or opening movements on a rigid workpiece or a fixed workpiece stop under constant conditions.
Repeat accuracy (positioning, unidirectional)
defined as the spread of the actual position of the base jaws after 100 consecutive movements to a target position from the same direction under constant conditions.
Repeat accuracy (positioning, bi-directional)
defined as the spread of the actual position of the base jaws after 100 consecutive movements to a target position from both directions under constant conditions.
Workpiece weight
is calculated for force-fit gripping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. For form-fit or capture gripping, there are significantly higher permissible workpiece weights.
Closing and opening times
are movement times of the base jaws only, without application-specific gripper fingers. PLC reaction times are not included in the above-mentioned times and must be taken into consideration when determining cycle times.
Operating principle
Rack and pinion principle
Housing material
Aluminum alloy, coated
Base jaw material
Steel
Actuation
servo-electric, via brushless DC servomotor
Warranty
24 months
Service life characteristics
on request
Scope of delivery
Gripper including safety information and accessory kit with centering sleeves for gripper and finger mounting. Product-specific instructions and software can be downloaded at schunk.com/downloads-manuals and schunk.com/downloads-software.