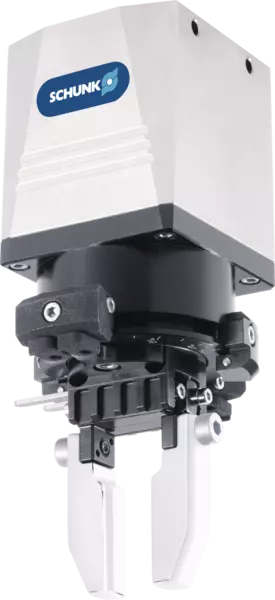
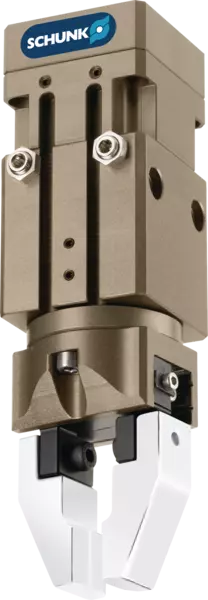
We offer gripper swivel modules by default as compact, modular designed parallel, centric, and angular gripper swivel modules. For quick positioning processes of workpieces with different weights in confined spaces. They can be used in a wide range of applications, from loading and unloading workpiece carriers to insertion operations in assembly processes and picking of finished goods in covering boxes. Furthermore, innovative design tweaks, such as the powerful rotor drive, as angle of rotation up to 180° and end-position and cushioning adjustment are combined with state-of-the-art production technology to give the grippers robust reliability and precision, therefore making them safe investments with a long service life.
There are seven different ways to maintain force and/or position when energy is lost.
AS: Spring-closing/IS: Spring-opening The conventional version for maintaining gripping force with a spring ensures a minimum gripping force even in the event of a pressure loss. In the AS variant this acts as a closing force, and in the IS variant as an opening force.
S: Spring-closing/spring-opening In the S variant, depending on the design/configuration of the top jaws, the spring built into the gripper can be used to provide either a closing force or an opening force.
is calculated for force-fit clamping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. In the case of form-fit gripping, significatnly higher permissible workpiece weights are possible.
Example: - For the catalog-specified workpiece weight of 5 kg Gripping force of the gripper 1,000 N Coefficient of friction μ 0.1; safety factor 2; g 9.81
Combinaison de rotation et de préhension compacte comprenant un entraînement rotatif puissant, un amortissement des fins de course et une pince de préhension parallèle à 2 doigts.