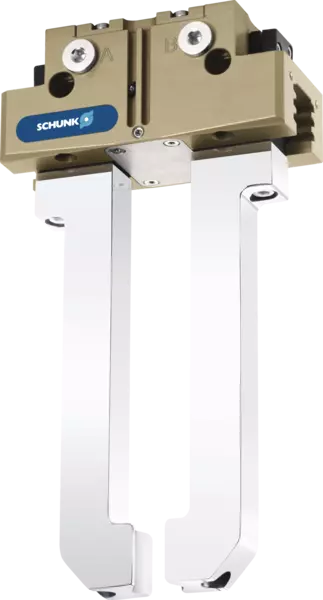
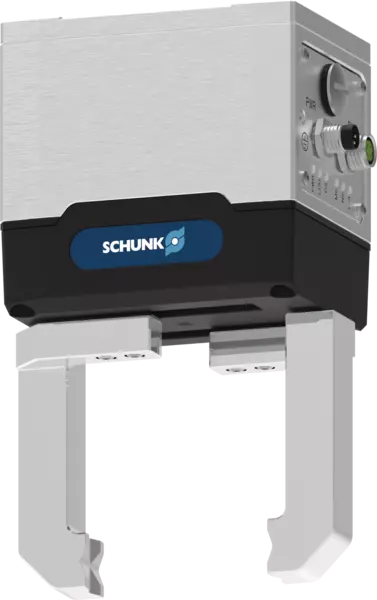
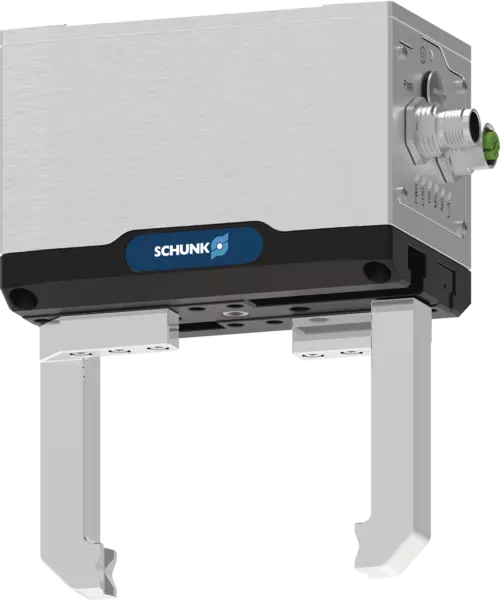
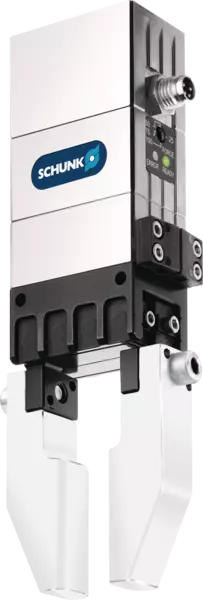
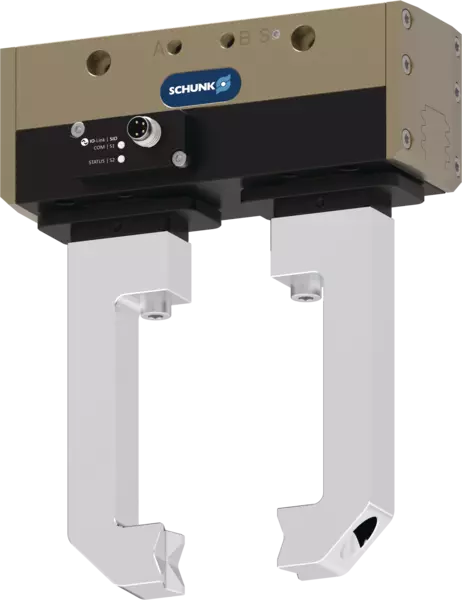
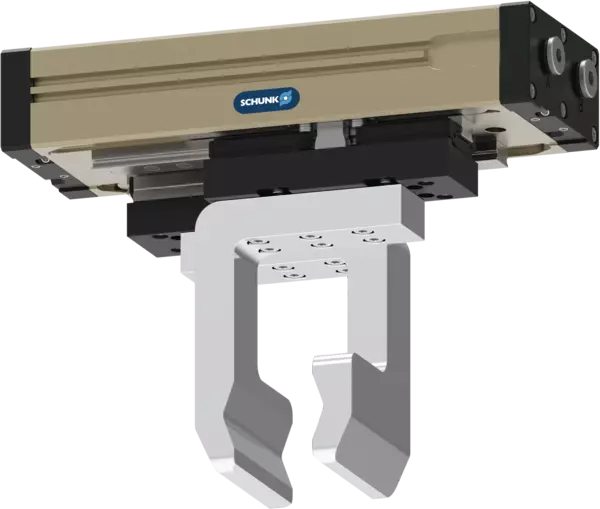
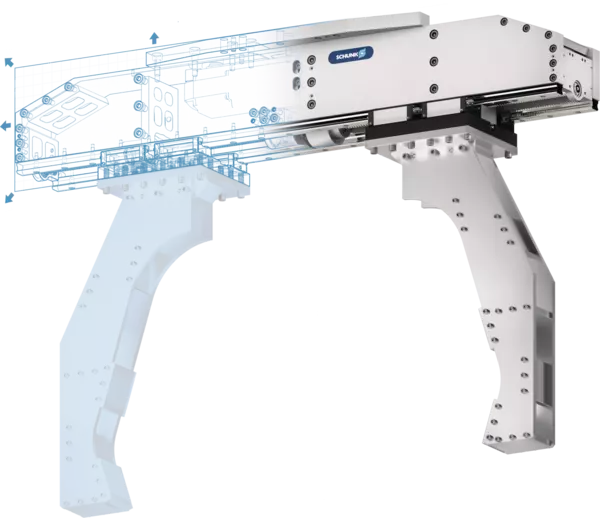
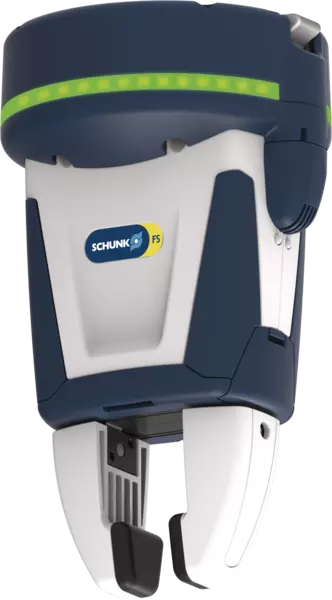
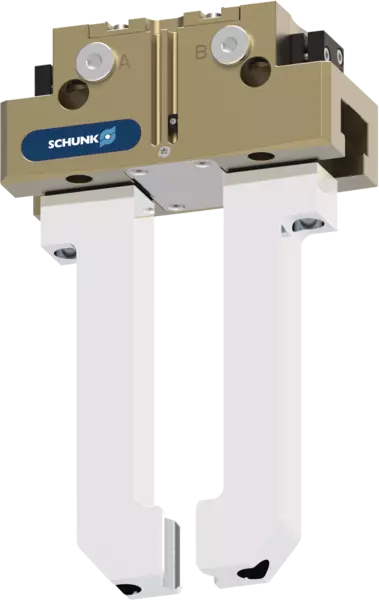
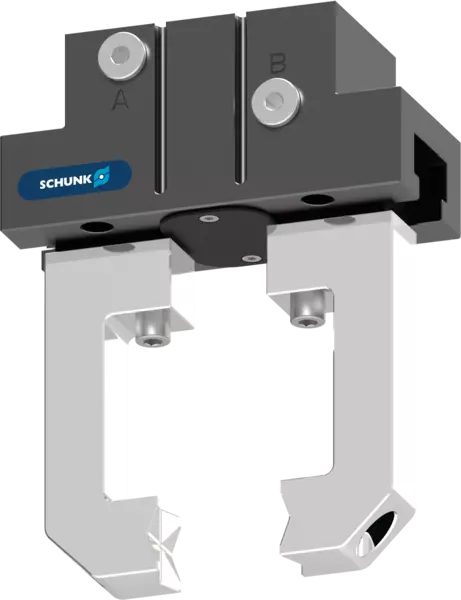
Our standard parallel grippers include small parts, universal, long-stroke, and sealed grippers for safe and precise handling of workpieces. They can handle workpieces with weights of anywhere between a few grams and 80 kilograms, and are suitable for many applications, from the cleanroom to potentially explosive work areas. The ability to equip the grippers with inductive sensor systems, magnetic switches or workpiece-specific gripper fingers improves their functionality, process reliability, and productivity. Furthermore, innovative design tweaks, such as multi-tooth guidance, are combined with state-of-the-art production technology to make them robust and reliable and therefore safe investment with a long service life.
There are seven different ways to maintain force and/or position when energy is lost.
AS: Spring-closing/IS: Spring-opening The conventional version for maintaining gripping force with a spring ensures a minimum gripping force even in the event of a pressure loss. In the AS variant this acts as a closing force, and in the IS variant as an opening force.
S: Spring-closing/spring-opening In the S variant, depending on the design/configuration of the top jaws, the spring built into the gripper can be used to provide either a closing force or an opening force.
The ambient temperature describes the temperature of the air or the direct operating environment in which a gripper is operated (and not the workpiece temperature, as this is normally significantly higher than the ambient temperature). We also offer special solutions for ambient temperatures above 130 °C. We would be happy to review your use case based on your specific process data.
is calculated for force-fit clamping with a coefficient of static friction of 0.1 and a safety factor of 2 against workpiece slippage at acceleration due to gravity g. In the case of form-fit gripping, significatnly higher permissible workpiece weights are possible.
Example: - For the catalog-specified workpiece weight of 5 kg Gripping force of the gripper 1,000 N Coefficient of friction μ 0.1; safety factor 2; g 9.81
For supported robot systems, we provide specific adapter plates, cable kits, and software plug-ins. This simplifies a standardized mechanical connection as well as software commissioning and integration. Is your target system not listed? Please contact us!
For supported control systems, we provide specific software resources (e.g., function blocks or parameter sets). This simplifies software commissioning and integration. Is your target system not listed? Please contact us!