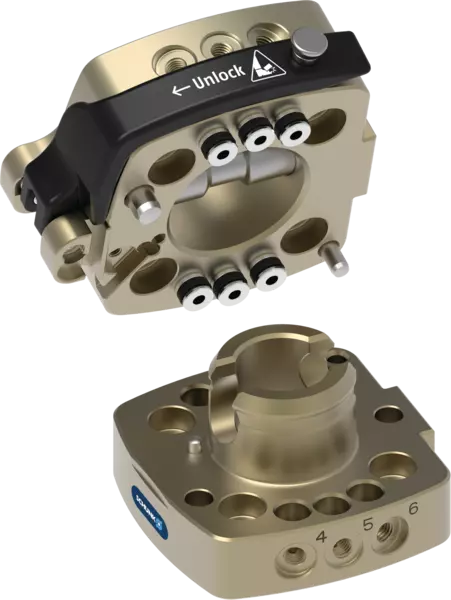
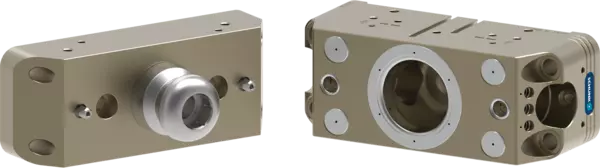
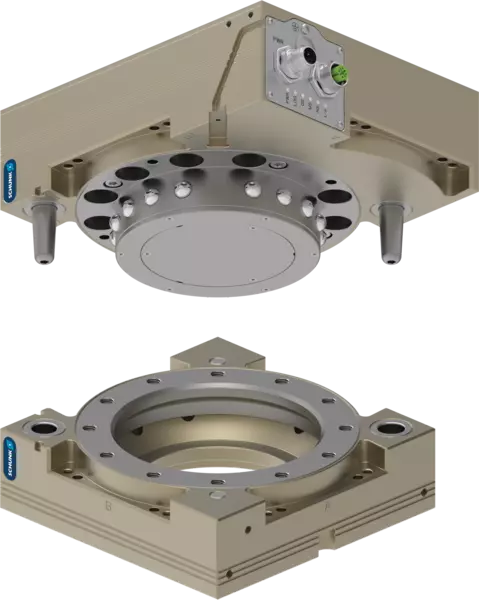
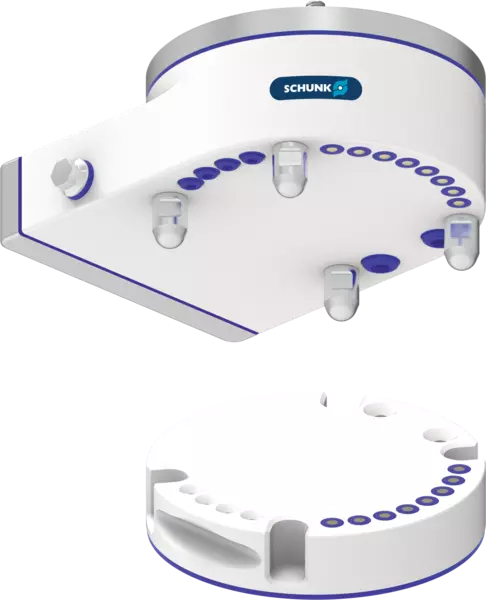
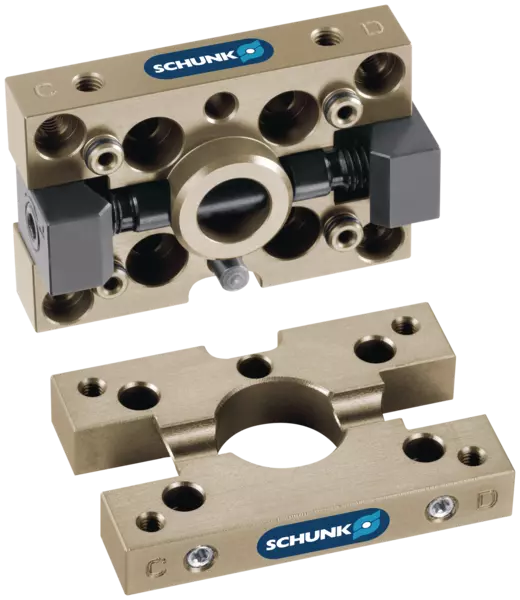
Using SCHUNK tool changers on robot front ends increases your application's versatility, efficiency, cycle time, and process reliability. Automatic and manual tool changers enable grippers, tools and other effectors to be changed quickly. In the field of automation, SCHUNK also offers the a broad portfolio of components for robot applications, from handling small components to heavy loads.
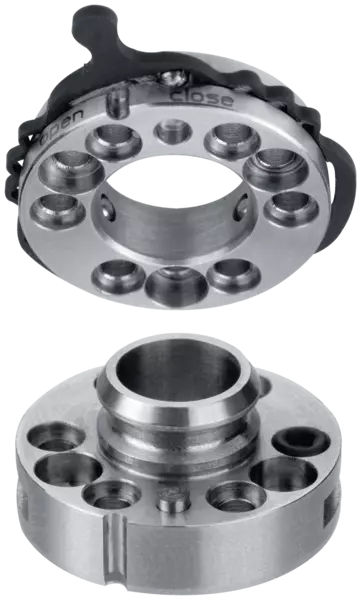
Ein Wechselsystem besteht aus zwei Komponenten. Die am Roboter befestigte Komponente wird roboterseitig angebracht. Die Komponente verbunden mit dem Werkzeug wird werkzeugseitig angebracht.
Ein Wechselsystem besteht aus zwei Komponenten. Die am Roboter befestigte Komponente wird roboterseitig angebracht. Die Komponente verbunden mit dem Werkzeug wird werkzeugseitig angebracht.
Zahlreiche Robot PLUS Produkte sind standardmäßig vorbereitet, um direkt an einen ISO 9409-1 Flansch eines Roboters geschraubt zu werden.
Beispiel: ISO 9409-1-125-6-M10 ISO 9409-1 beschreibt die Norm 125 entspricht dem Lochkreisdurchmesser 6- M10: 6 M10 Schrauben in Einheit vorinstalliert
Dieser Wert beschreibt, mit welcher Kraft der Wechselkopf den Wechseladapter anzieht. Abhängig vom System gilt der Wert bei unterschiedlichen Abständen zwischen Wechselkopf und Wechseladapter, siehe nachfolgend:
CPS: Wert gilt bei einem Abstand von 0,5 mm zwischen Wechselkopf und Wechseladapter
CPB: gilt bei einem Abstand von 0 mm zwischen Wechselkopf und Wechseladapter.
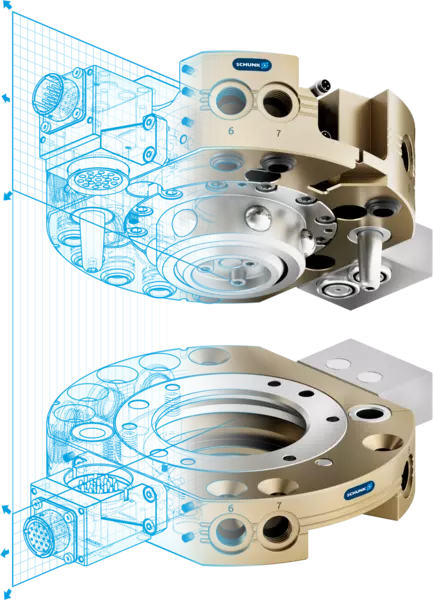
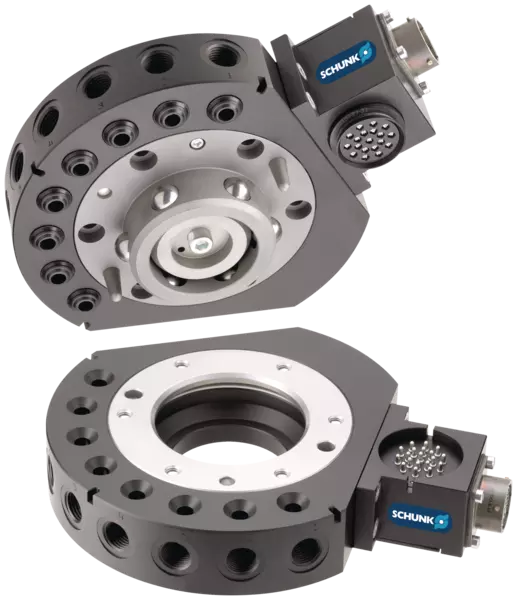
Pneumatically actuated tool changer with self-retaining function in the event of a loss of compressed air, the integrated piston spring ensures that gap formation is minimized.
Pneumatically actuated tool changer with self-retaining function in the event of a loss of compressed air, the integrated piston spring ensures that gap formation is minimized.
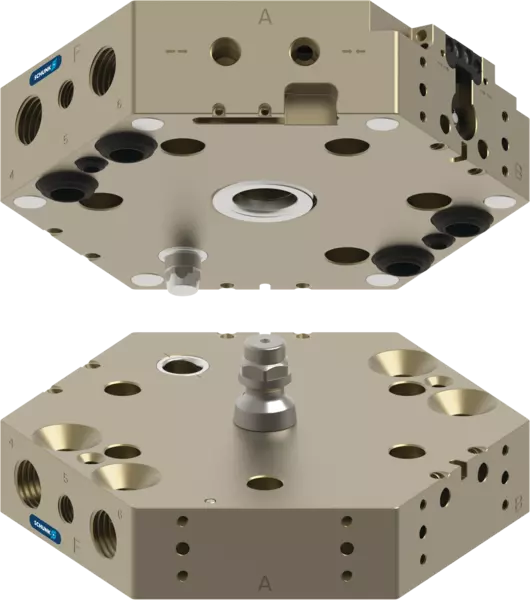
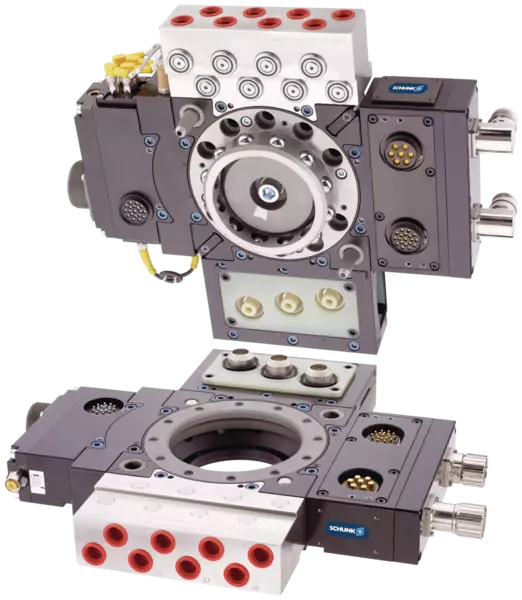
Electrically actuated tool changer with self-retaining function in the event of electrical power failure and an integrated sensor system for monitoring locking and tool presence.